.png)
















- Obecnie brak na stanie


9.7:1 Metal Gearmotor 25Dx48L mm HP with 48 CPR Encoder
9.7:1 Metal Gearmotor 25Dx48L mm HP with 48 CPR Encoder
This cylindrical, 2.38" x 0.98" x 0.98" gearmotor uses a brushed DC motor with extra-strong magnets and a 9.68:1 metal gearbox to deliver a lot of power in a relatively small package. It has an integrated 48 CPR quadrature encoder on the motor shaft, which provides 465 counts per revolution of the gearbox’s output shaft. These units have a 0.315"-long, 4 mm-diameter D-shaped output shaft. We also carry a lower-power version of this gearmotor and a version without an encoder.
Key specs at 6 V: 1010 RPM and 450 mA free-run, 17 oz-in (1.2 kg-cm) and 6 A stall.
This brushed DC gearmotor is available in high- and low-power versions in a number of gear ratios. Many other gear ratios are also available without an encoder.
| Gear Ratio | Speed @ 6V | Stall Torque @ 6V | Stall Current @ 6V |  With Encoder |  Without Encoder |
|---|---|---|---|---|---|
| 4.4:1 | 2020 RPM | 8 oz-in | 6 A | 25Dx48L mm HP | |
| 1280 RPM | 5 oz-in | 2.2 A | 25Dx48L mm | ||
| 9.7:1 | 1010 RPM | 17 oz-in | 6 A | 25Dx48L mm HP | 25Dx48L mm HP |
| 580 RPM | 11 oz-in | 2.2 A | 25Dx48L mm | 25Dx48L mm | |
| 20.4:1 | 480 RPM | 36 oz-in | 6 A | 25Dx50L mm HP | |
| 275 RPM | 24 oz-in | 2.2 A | 25Dx50L mm | ||
| 34:1 | 285 RPM | 60 oz-in | 6 A | 25Dx52L mm HP | 25Dx52L mm HP |
| 165 RPM | 40 oz-in | 2.2 A | 25Dx52L mm | 25Dx52L mm | |
| 47:1 | 210 RPM | 80 oz-in | 6 A | 25Dx52L mm HP | 25Dx52L mm HP |
| 120 RPM | 50 oz-in | 2.2 A | 25Dx52L mm | 25Dx52L mm | |
| 75:1 | 130 RPM | 130 oz-in | 6 A | 25Dx54L mm HP | 25Dx54L mm HP |
| 75 RPM | 85 oz-in | 2.2 A | 25Dx54L mm | 25Dx54L mm | |
| 99:1 | 100 RPM | 160 oz-in | 6 A | 25Dx54L mm HP | |
| 57 RPM | 110 oz-in | 2.2 A | 25Dx54L mm | ||
| 172:1 | 57 RPM | 260 oz-in | 6 A | 25Dx56L mm HP | |
| 33 RPM | 170 oz-in | 2.2 A | 25Dx56L mm | 25Dx56L mm | |
| 227:1 | 25 RPM | 220 oz-in | 2.2 A | 25Dx56L mm | |
| 378:1 | 15 RPM | 250 oz-in | 2.2 A | 25Dx58L mm | |
| 499:1 | 12 RPM | 300 oz-in | 2.2 A | 25Dx58L mm |
Note: At some of the higher gear ratios, these motors can generate enough torque to damage themselves. Any torque greater than about 250 oz-in (18 kg-cm) is likely to damage the gearbox, so we recommend that you avoid stalling the 172:1 HP, 227:1, 378:1, and 499:1 versions of these motors at 6 V.
These motors are intended for use at 6 V. In general, these kinds of motors can run at voltages above and below this nominal voltage, so they should comfortably operate in the 3 – 9 V range, though they can begin rotating at voltages as low as 1 V. Higher voltages could start negatively affecting the life of the motor.
These gearmotors have output shafts with a diameter of 4 mm. The Pololu universal aluminum mounting hub for 4mm shafts can be used to mount our larger Pololu wheels (60mm-, 70mm-, 80mm-, and 90mm-diameter) or custom wheels and mechanisms to the gearmotor’s output shaft (see the left picture below). These are the same type of motors used in the Wild Thumper all-terrain chassis, and the gearbox’s output shaft works directly with the 120mm-diameter Wild Thumper wheels.
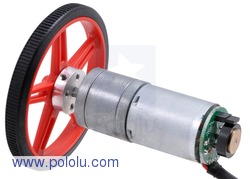 |
| 25D mm metal gear motor with 48 CPR encoder and Pololu 60×8mm wheel. |
|---|
The face plate has two mounting holes threaded for M3 screws. You can use our custom-designed 25D mm metal gearmotor bracket (shown in the picture below) to mount the gearmotor to your project via these mounting holes and the screws that come with the bracket.
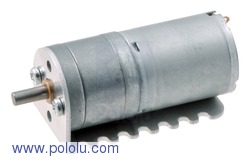 |
| Pololu 25D mm gearmotor with bracket. |
|---|
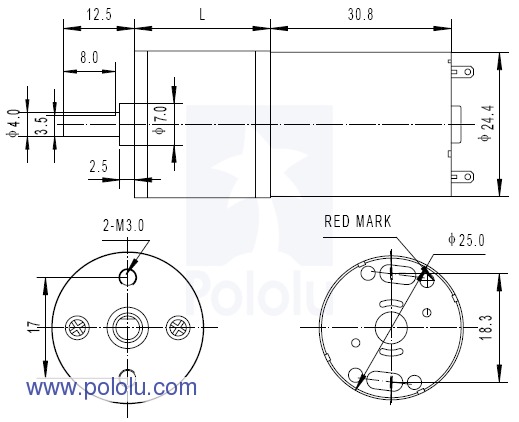
The diagram below shows the dimensions (in mm) of the 25D mm line of gearmotors. The value of L is shown in the table below.
|
|
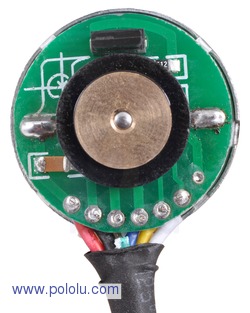 |
| 25D mm metal gearmotor with 48 CPR encoder. |
|---|
A two-channel Hall effect encoder is used to sense the rotation of a magnetic disk on a rear protrusion of the motor shaft. The quadrature encoder provides a resolution of 48 counts per revolution of the motor shaft. To compute the counts per revolution of the gearbox output, multiply the gear ratio by 48. The motor/encoder has six color-coded, 11" (28 cm) leads:
| Color | Function |
|---|---|
| Black | motor power |
| Red | motor power |
| Blue | Hall sensor Vcc (3.5 – 20 V) |
| Green | Hall sensor GND |
| Yellow | Hall sensor A output |
| White | Hall sensor B output |
These leads have stripped, unterminated ends that can be soldered or crimped to make solder free connectors. The Hall sensor requires an input voltage, Vcc, between 3.5 and 20 V and draws a maximum of 10 mA. The A and B outputs are square waves from 0 V to Vcc approximately 90° out of phase. The frequency of the transitions tells you the speed of the motor, and the order of the transitions tells you the direction. The following oscilloscope capture shows the A and B (yellow and white) encoder outputs using a motor voltage of 6 V and a Hall sensor Vcc of 5 V:
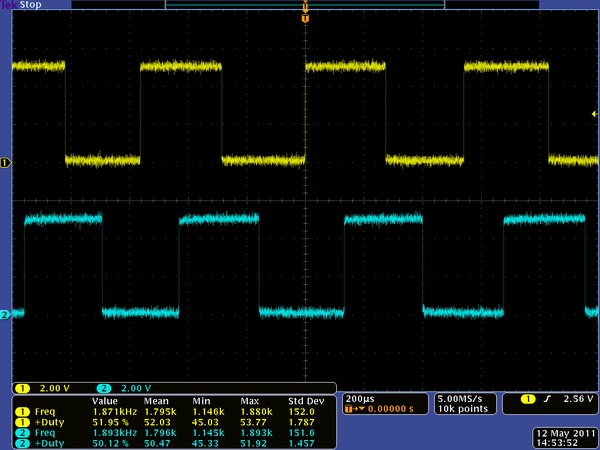 |
| Encoder A and B outputs for 25D mm HP metal gearmotor with 48 CPR encoder (motor running at 6 V). |
|---|
By counting both the rising and falling edges of both the A and B outputs, it is possible to get 48 counts per revolution of the motor shaft. Using just a single edge of one channel results in 12 counts per revolution of the motor shaft, so the frequency of the A output in the above oscilloscope capture is 12 times the motor rotation frequency.
May 5, 2012 Update: We are transitioning to encoders with leads terminated by a 1×6 0.1” female header. If you receive an encoder with such a header, you can pull the crimped wires out of the header or cut the header off if you just want the individual wires.
We offer a wide selection of metal gearmotors that offer different combinations of speed and torque. Our metal gearmotor comparison table can help you find the motor that best meets your project’s requirements.
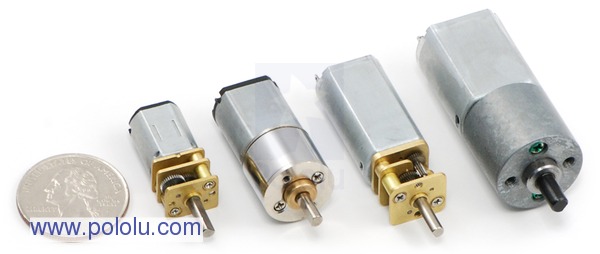 |
| Some of the Pololu metal gearmotors. |
|---|
Cechy
Producent
Osoba odpowiedzialna
Zestaw ewaluacyjny z układem Zynq-7000 APSoC integrujący procesor oparty na ARM Cortex-A9 z układem FPGA Artix-7. Udostępnia dwa złącza interfejsu SYZYGY umożliwiające współpracę z szybkimi systemami modułowymi. Zestaw pracuje pod kontrolą systemu Linux. Digilent Eclypse Z7 410-393
Brak towaru
Dwukanałowy konwerter ADC zgodny ze standardem SYZYGY. Moduł może jednocześnie odbierać dwa sygnały 25V z 14-bitową rozdzielczością i częstotliwością próbkowania do 100MS/s. Moduł jest kompatybilny z zestawami ewaluacyjnymi Eclypse Z7 oraz Genesys ZU. Digilent Zmod Scope 1410-105 (410-396)
Brak towaru
Dwukanałowy konwerter DAC zgodny ze standardem SYZYGY. Moduł może jednocześnie generować dwa sygnały 5V z 14-bitową rozdzielczością i częstotliwością próbkowania do 100MS/s. Moduł jest kompatybilny z zestawami ewaluacyjnymi Eclypse Z7 oraz Genesys ZU. Digilent Zmod AWG 1411 410-397
Brak towaru
Obiektyw do kamer ArduCAM ze zmiennym obiektywem M12 przeznaczonych dla Raspberry Pi. Charakteryzuje się ogniskową 8mm, kątem widzenia 40/45° oraz formatem 1/3. ArduCAM LS-8020
Brak towaru
BeagleBone AI to minikomputer z procesorem AM5729, do jego dyspozycji jest 1 GB pamięci RAM DDR3L. Został stworzony w celu poznawania zagadnień związanych ze sztuczną inteligencją. BBBONE-AI
Brak towaru
NanoPi M4V2 to komputer jednoukładowy firmy FriendlyELEC. Zastosowano w nim pamięć RAM typu LPDDR4 oraz dodano m.in.: mikroprzełączniki POWER i RECOVERY i wejście mikrofonowe.
Brak towaru
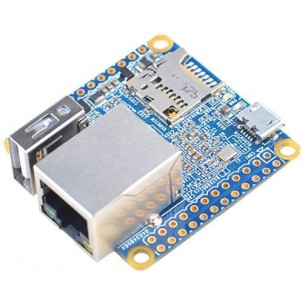
NanoPI NEO jest jednopłytkowym układem od FriendlyELEC o pamięci RAM 256 MB, z powodzeniem konkurującym z układami stworzonymi przez potentata w tej dziedzinie Raspberry Pi. Od płytki Raspberry Pi Zero jest o 25% mniejszy oraz tańszy przy analogicznych możliwościach.
Brak towaru
Minikomputer z czterordzeniowym układem Allwinner H3 (ARM Cortex-A7). Wyposażony został w pamięć RAM o pojemności 512 MB, port Ethernet i 3 interfejsy USB 2.0. NanoPi NEO-LTS 512MB
Brak towaru
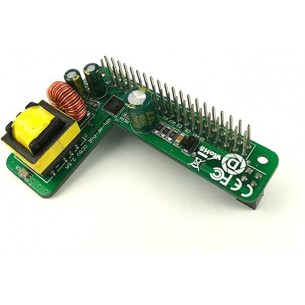
Nakładka HAT PoE do Raspberry Pi. Pozwala wykorzystać interfejs PoE do zasilania minikomputera przez kabel Ethernet
Brak towaru
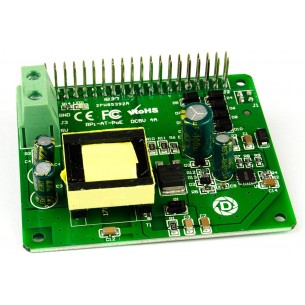
Nakładka HAT PoE do Raspberry Pi. Pozwala wykorzystać interfejs PoE do zasilania minikomputera przez kabel Ethernet
Brak towaru
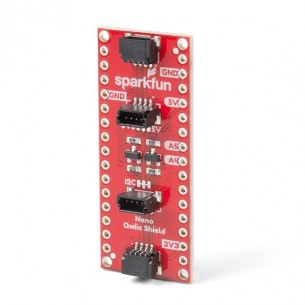
Shield który umożliwia podłączenie modułów zgodnych z SparkFun Qwiic do płytki Arduino Nano. Połączenie z płytką Arduino odbywa się poprzez magistralę I2C. SparkFun DEV-16130
Brak towaru
SparkFun Qwiic Shield dla Thing Plus zapewnia łatwy w montażu sposób na dodanie złącz Qwiic do płytek z rodziny Thing Plus oraz Feather. Komunikacja odbywa się za pomocą intefejsu I2C. Sparkfun DEV-16138
Brak towaru
Cytron 0.8Amp 5V-26V DC Motor Driver Shield - dwukanałowy sterownik silników DC dla Arduino
Brak towaru
Brak towaru
Moduł z czytnikiem kart microSD
Brak towaru
Brak towaru
9.7:1 Metal Gearmotor 25Dx48L mm HP with 48 CPR Encoder