.png)
















- Obecnie brak na stanie


47:1 Metal Gearmotor 25Dx52L mm with 48 CPR Encoder
47:1 Metal Gearmotor 25Dx52L mm with 48 CPR Encoder
This cylindrical, 2.54" x 0.98" x 0.98" brushed DC gearmotor with a 46.851:1 metal gearbox is a lower-current alternative to the HP version. It has an integrated 48 CPR quadrature encoder on the motor shaft, which provides 2249 counts per revolution of the gearbox’s output shaft. These units have a 0.315"-long, 4 mm-diameter D-shaped output shaft. This gearmotor is also available without an encoder.
Key specs at 6 V: 120 RPM and 80 mA free-run, 50 oz-in (3.6 kg-cm) and 2.2 A stall.
This brushed DC gearmotor is available in high- and low-power versions in a number of gear ratios. Many other gear ratios are also available without an encoder.
| Gear Ratio | Speed @ 6V | Stall Torque @ 6V | Stall Current @ 6V |  With Encoder |  Without Encoder |
|---|---|---|---|---|---|
| 4.4:1 | 2020 RPM | 8 oz-in | 6 A | 25Dx48L mm HP | |
| 1280 RPM | 5 oz-in | 2.2 A | 25Dx48L mm | ||
| 9.7:1 | 1010 RPM | 17 oz-in | 6 A | 25Dx48L mm HP | 25Dx48L mm HP |
| 580 RPM | 11 oz-in | 2.2 A | 25Dx48L mm | 25Dx48L mm | |
| 20.4:1 | 480 RPM | 36 oz-in | 6 A | 25Dx50L mm HP | |
| 275 RPM | 24 oz-in | 2.2 A | 25Dx50L mm | ||
| 34:1 | 285 RPM | 60 oz-in | 6 A | 25Dx52L mm HP | 25Dx52L mm HP |
| 165 RPM | 40 oz-in | 2.2 A | 25Dx52L mm | 25Dx52L mm | |
| 47:1 | 210 RPM | 80 oz-in | 6 A | 25Dx52L mm HP | 25Dx52L mm HP |
| 120 RPM | 50 oz-in | 2.2 A | 25Dx52L mm | 25Dx52L mm | |
| 75:1 | 130 RPM | 130 oz-in | 6 A | 25Dx54L mm HP | 25Dx54L mm HP |
| 75 RPM | 85 oz-in | 2.2 A | 25Dx54L mm | 25Dx54L mm | |
| 99:1 | 100 RPM | 160 oz-in | 6 A | 25Dx54L mm HP | |
| 57 RPM | 110 oz-in | 2.2 A | 25Dx54L mm | ||
| 172:1 | 57 RPM | 260 oz-in | 6 A | 25Dx56L mm HP | |
| 33 RPM | 170 oz-in | 2.2 A | 25Dx56L mm | 25Dx56L mm | |
| 227:1 | 25 RPM | 220 oz-in | 2.2 A | 25Dx56L mm | |
| 378:1 | 15 RPM | 250 oz-in | 2.2 A | 25Dx58L mm | |
| 499:1 | 12 RPM | 300 oz-in | 2.2 A | 25Dx58L mm |
Note: At some of the higher gear ratios, these motors can generate enough torque to damage themselves. Any torque greater than about 250 oz-in (18 kg-cm) is likely to damage the gearbox, so we recommend that you avoid stalling the 172:1 HP, 227:1, 378:1, and 499:1 versions of these motors at 6 V.
These motors are intended for use at 6 V. In general, these kinds of motors can run at voltages above and below this nominal voltage, so they should comfortably operate in the 3 – 9 V range, though they can begin rotating at voltages as low as 1 V. Higher voltages could start negatively affecting the life of the motor.
These gearmotors have output shafts with a diameter of 4 mm. The Pololu universal aluminum mounting hub for 4mm shafts can be used to mount our larger Pololu wheels (60mm-, 70mm-, 80mm-, and 90mm-diameter) or custom wheels and mechanisms to the gearmotor’s output shaft (see the left picture below). These are the same type of motors used in the Wild Thumper all-terrain chassis, and the gearbox’s output shaft works directly with the 120mm-diameter Wild Thumper wheels.
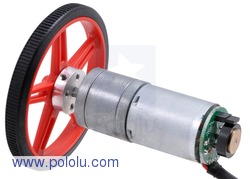 |
| 25D mm metal gear motor with 48 CPR encoder and Pololu 60×8mm wheel. |
|---|
The face plate has two mounting holes threaded for M3 screws. You can use our custom-designed 25D mm metal gearmotor bracket (shown in the picture below) to mount the gearmotor to your project via these mounting holes and the screws that come with the bracket.
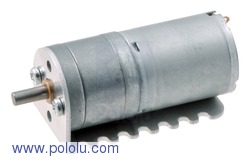 |
| Pololu 25D mm gearmotor with bracket. |
|---|
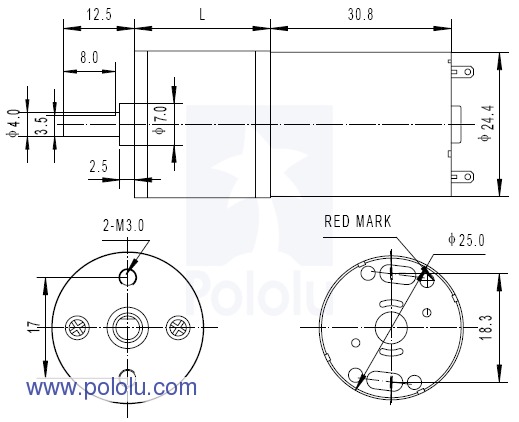
The diagram below shows the dimensions (in mm) of the 25D mm line of gearmotors. The value of L is shown in the table below.
|
|
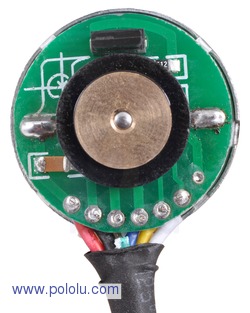 |
| 25D mm metal gearmotor with 48 CPR encoder. |
|---|
A two-channel Hall effect encoder is used to sense the rotation of a magnetic disk on a rear protrusion of the motor shaft. The quadrature encoder provides a resolution of 48 counts per revolution of the motor shaft. To compute the counts per revolution of the gearbox output, multiply the gear ratio by 48. The motor/encoder has six color-coded, 11" (28 cm) leads:
| Color | Function |
|---|---|
| Black | motor power |
| Red | motor power |
| Blue | Hall sensor Vcc (3.5 – 20 V) |
| Green | Hall sensor GND |
| Yellow | Hall sensor A output |
| White | Hall sensor B output |
These leads have stripped, unterminated ends that can be soldered or crimped to make solder free connectors. The Hall sensor requires an input voltage, Vcc, between 3.5 and 20 V and draws a maximum of 10 mA. The A and B outputs are square waves from 0 V to Vcc approximately 90° out of phase. The frequency of the transitions tells you the speed of the motor, and the order of the transitions tells you the direction. The following oscilloscope capture shows the A and B (yellow and white) encoder outputs using a motor voltage of 6 V and a Hall sensor Vcc of 5 V:
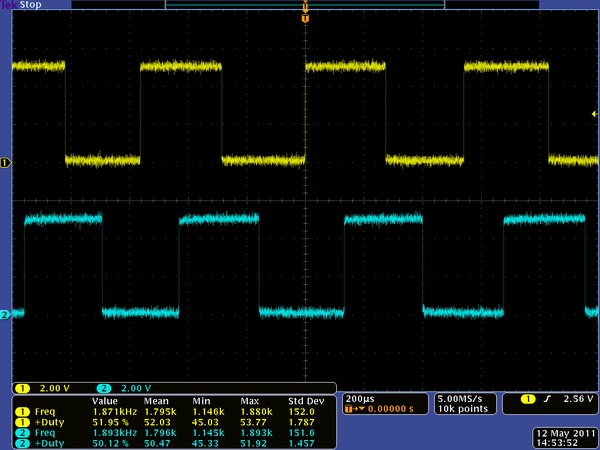 |
| Encoder A and B outputs for 25D mm HP metal gearmotor with 48 CPR encoder (motor running at 6 V). |
|---|
By counting both the rising and falling edges of both the A and B outputs, it is possible to get 48 counts per revolution of the motor shaft. Using just a single edge of one channel results in 12 counts per revolution of the motor shaft, so the frequency of the A output in the above oscilloscope capture is 12 times the motor rotation frequency.
May 5, 2012 Update: We are transitioning to encoders with leads terminated by a 1×6 0.1” female header. If you receive an encoder with such a header, you can pull the crimped wires out of the header or cut the header off if you just want the individual wires.
We offer a wide selection of metal gearmotors that offer different combinations of speed and torque. Our metal gearmotor comparison table can help you find the motor that best meets your project’s requirements.
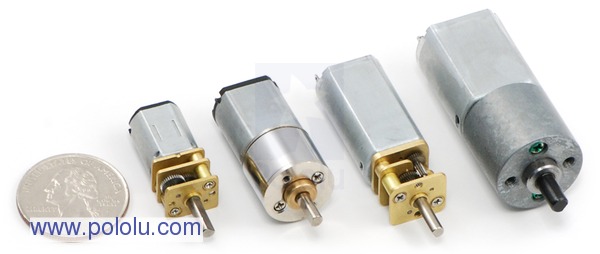 |
| Some of the Pololu metal gearmotors. |
|---|
Cechy
Producent
Osoba odpowiedzialna
Wzmacniacz / konwerter sygnału z belek tensometrycznych, pozwala na cyfrowy odczyt wartości masy obciążającej tensometr, max. 80 próbek / sekundę
Brak towaru
Brak towaru
Moduł Bluetooth do montażu w technologii SMD z w pełni konfigurowalnym interfejsem UART - prędkość transferu do 2 Mb/s. WRL-11786
Brak towaru
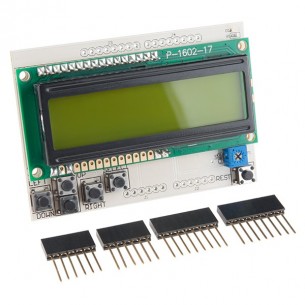
Płytka z wyświetlaczem o organizacji 16 x 2 znaków i pięcioma przyciskami (odczytywanymi przez ADC mikrokontrolera), zgodna z Arduino; w zestawie ze złączami (do samodzielnego wlutowania). DEV-13293
Brak towaru
Zestaw do budowy robota SparkFun Inventors Kit wyposażony m.in. w dwupłytową platformę, dwa silniki, komplet czujników, kontroler RedBot. ROB-12649
Brak towaru
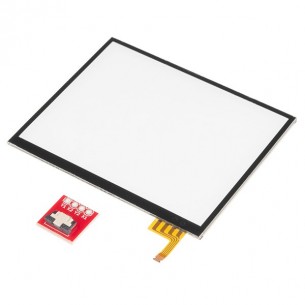
Zestaw SparkFun Nintendo DS Screen Kit wraz z płytką do podłączenia (adapter ZIF -> goldpin). LCD-13631
Brak towaru
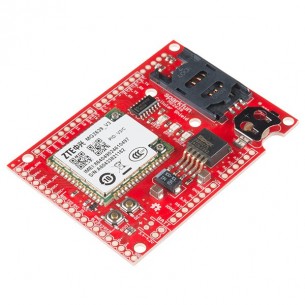
Rozszerzenie SparkFun Cellular Shield z modułem MG2639 umożliwia transmisję danych i głosu przez GSM/GPRS oraz korzystanie z odbiornika GPS. Można w kilka chwil stworzyć skuteczny lokalizator GPS. (CEL-13120)
Brak towaru
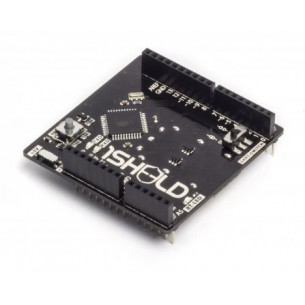
Wyobraź sobie Arduino Shield, który może być wykorzystać smartfon z systemem Android jako LCD, GPS, Wifi i pełnić wiele innych funkcji. 1sheeld łączy się za pomocą Bluetootha z mobilną aplikacją pozwalającą na korzystanie poprzez Arduino z funkcji smartfonów z systemem Android.
Brak towaru
Moduł z analogowym czujnikiem światła UV ML8511. Umożliwia pomiar natężenia promieniowania dla fali UV-A (320-400nm) i UV-B (280-320nm). Interfejs analogowy. DFRobot SEN0175
Brak towaru
C Tinkering Kit to zestaw, który pomoże Ci w łatwy sposób utworzyć ciekawe projekty z wykorzystaniem Odroida-C1/C1+/C0/C2. Zestaw zawiera m.in. 40-pinową płytkę prototypową T-breakout board, płytkę stykową z 630 punktami, 40-pinowy kabel IDC o długości 10 cm, 40-pinowy przewód połączeniowy typu Male-to-Male o długości 17 cm, diody LED oraz rezystory
Brak towaru
Development Boards & Kits - ARM SAMD10 Xplained Mini evaluation kit, Microchip
Brak towaru
Moduł współpracujący z Arduino Ethernet Shield 2 oraz Arduino Ethernet. Umożliwia podłączenie zasilania do Arduino z sieci Ethernet. Zgodny ze standardem IEEE 802.3af Power-over-Ethernet.
Brak towaru
Moduł współpracujący z Arduino Yun. Umożliwia podłączenie zasilania do Arduino z sieci Ethernet. Zgodny ze standardem IEEE 802.3af Power-over-Ethernet.
Brak towaru
Obudowa dla komputera Banana Pro wykonana z przezroczystego tworzywa, spód obudowy jest w kolorze czarnym. Obudowa do samodzielnego zmontowania
Brak towaru
Obudowa dla komputera Banana PI M1+ wykonana z przezroczystego tworzywa. Obudowa do samodzielnego zmontowania
Brak towaru
Obudowa dla komputera Banana PI M2 wykonana z przezroczystego tworzywa. Obudowa do samodzielnego zmontowania
Brak towaru
47:1 Metal Gearmotor 25Dx52L mm with 48 CPR Encoder