- Out-of-Stock

.png)

19:1 Metal Gearmotor 37Dx52L mm with 64 CPR Encoder
19:1 Metal Gearmotor 37Dx52L mm with 64 CPR Encoder
This 2.54" × 1.45" × 1.45" gearmotor is a powerful 12V brushed DC motor with a 18.75:1 metal gearbox and an integrated quadrature encoder that provides a resolution of 64 counts per revolution of the motor shaft, which corresponds to 1200 counts per revolution of the gearbox’s output shaft. These units have a 0.61"-long, 6 mm-diameter D-shaped output shaft. This gearmotor is also available without an encoder.
Key specs at 12 V: 500 RPM and 300 mA free-run, 84 oz-in (5 kg-cm) and 5 A stall.
This powerful brushed DC gearmotor is available in six different gear ratios and features an integrated quadrature encoder with 64 counts per revolution (CPR) of the motor shaft. A version without the encoder is also available.
| Gear Ratio | Speed @ 12V | Stall Torque @ 12V | Stall Current @ 12V |  With Encoder |  Without Encoder |
|---|---|---|---|---|---|
| 19:1 | 500 RPM | 84 oz-in | 5 A | 37Dx52L mm | 37Dx52L mm |
| 29:1 | 350 RPM | 110 oz-in | 5 A | 37Dx52L mm | 37Dx52L mm |
| 50:1 | 200 RPM | 170 oz-in | 5 A | 37Dx54L mm | 37Dx54L mm |
| 67:1 | 150 RPM | 200 oz-in | 5 A | 37Dx54L mm | 37Dx54L mm |
| 100:1 | 100 RPM | 220 oz-in | 5 A | 37Dx57L mm | 37Dx57L mm |
| 131:1 | 80 RPM | 250 oz-in | 5 A | 37Dx57L mm | 37Dx57L mm |
These motors are intended for use at 12 V, though the motor can begin rotating at voltages as low as 1 V.
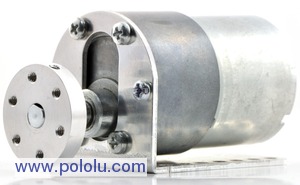
The face plate has six mounting holes evenly spaced around the outer edge threaded for M3 screws. These mounting holes form a regular hexagon and the centers of neighboring holes are 15.5 mm apart. You can use our custom 37D mm metal gearmotor bracket (shown in the left picture below) to mount the gearmotor to your project via these mounting holes and the screws that come with the bracket.
|
|
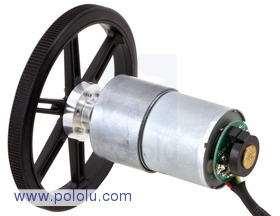
Please note that unlike our smaller metal gearmotors, these 37D mm gearmotors have output shafts with a diameter of 6 mm. The Pololu universal aluminum mounting hub for 6mm shafts can be used to mount our larger Pololu wheels (80mm- and 90mm-diameter) or custom wheels and mechanisms to the gearmotor’s output shaft (see the right picture above).
The diagram below shows the dimensions (in mm) of the 37D mm line of gearmotors. The value of X is 22 mm for the 19:1 37Dx52L mm and 29:1 37Dx52L mm versions, 24 mm for the 50:1 37Dx54L mm and 67:1 37Dx54L mm versions, and 26.5 mm for the 100:1 37Dx57L mm and 131:1 37Dx57L mm versions. Note that the encoder PCB and magnetic disc are not shown in this dimension diagram. The encoder assembly extends an additional 12.5 mm beyond the rear of the motor.
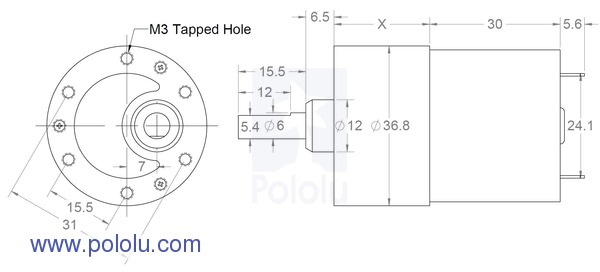 |
| 37D mm metal gearmotor dimensions (units in mm). |
|---|
Warning: Do not screw too far into the mounting holes as the screws can hit the gears. We recommend screwing no further than 3mm (1/8") into the screw hole.
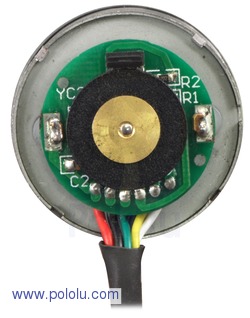 |
| 37D mm metal gearmotor with 64 CPR encoder. |
|---|
A two-channel Hall effect encoder is used to sense the rotation of a magnetic disk on a rear protrusion of the motor shaft. The quadrature encoder provides a resolution of 64 counts per revolution of the motor shaft. To compute the counts per revolution of the gearbox output, multiply the gear ratio by 64. The motor/encoder has six color-coded, 11" (28 cm) leads:
| Color | Function |
|---|---|
| Black | motor power |
| Red | motor power |
| Blue | Hall sensor Vcc (3.5 – 20 V) |
| Green | Hall sensor GND |
| Yellow | Hall sensor A output |
| White | Hall sensor B output |
These leads have stripped, unterminated ends that can be soldered or crimped to make solder free connectors. The Hall sensor requires an input voltage, Vcc, between 3.5 and 20 V and draws a maximum of 10 mA. The A and B outputs are square waves from 0 V to Vcc approximately 90° out of phase. The frequency of the transitions tells you the speed of the motor, and the order of the transitions tells you the direction. The following oscilloscope capture shows the A and B (yellow and white) encoder outputs using a motor voltage of 12 V and a Hall sensor Vcc of 5 V:
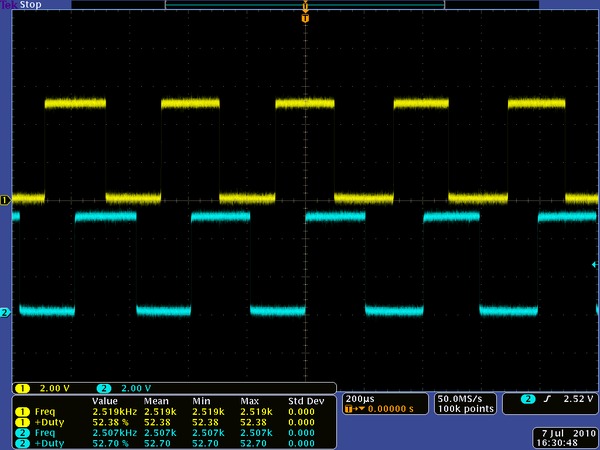 |
| Encoder A and B outputs for 37D mm metal gearmotor with 64 CPR encoder (motor running at 12 V). |
|---|
By counting both the rising and falling edges of both the A and B outputs, it is possible to get 64 counts per revolution of the motor shaft. Using just a single edge of one channel results in 16 counts per revolution of the motor shaft, so the frequency of the A output in the above oscilloscope capture is 16 times the motor rotation frequency.
July 9, 2012 Update: We are transitioning to encoders with leads terminated by a 1×6 0.1” female header. If you receive an encoder with such a header, you can pull the crimped wires out of the header or cut the header off if you just want the individual wires.
We offer a wide selection of metal gearmotors that offer different combinations of speed and torque. Our metal gearmotor comparison table can help you find the motor that best meets your project’s requirements.
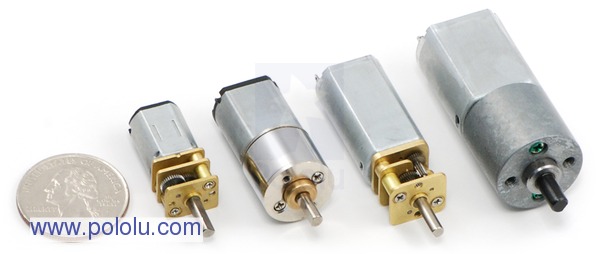 |
| Some of the Pololu metal gearmotors. |
|---|
 |
Pololu Universal Aluminum Mounting Hub for 6mm Shaft Pair, 4-40 Holes |
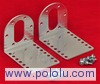 |
Pololu 37D mm Metal Gearmotor Bracket Pair |
 |
Pololu Wheel 90x10mm Pair - Black |
Manufacturer
Responsible person
EXTREME heat shrink tubing for electrical and mechanical insulation, diameter against shrinkage 5.0 mm; diameter after shrinkage 1.5 mm, a set of 10 pieces with a length of 1 meter
No product available!
The SparkFun ESP32 Thing Power Control Shield enables the ESP32 Thing to switch up to 5A of a DC load, providing a wide variety of options to control your next project! With a default voltage range of 5–28VDC, power can be connected to this shield in one of two ways. DEV-14155
No product available!
No product available!
RTL8211E-VL-CG, Integrated 10/100/1000 Gigabit Ethernet Transceiver, QFN-48
No product available!
The 30-core female-to-female connection wire with a length of 30 cm and a pitch of 2.54 mm provides reliable and flexible connections between modules and starter kits in DIY projects and prototypes
No product available!
A new version is available: VisionCB-STD v.2.0.
VisionCB-STD is a base board for VisionSOM-6UL (i.MX6 UL) and VisionSOM-6ULL (i.MX6 ULL) modules. The tile contains, among others Ethernet, USB connectors, connectors compatible with Arduino shields and Raspberry Pi hat, 5 buttons and 5 LEDs. VisionCB-STD
No product available!
Tactile switch, measuring 6x6 mm with a height of 5.0 mm, is a reliable component for surface mount (SMD) applications. It features a rated voltage of 12 V DC, a current of 50 mA, and a lifespan of up to 100,000 cycles. The switch has a travel distance of 0.25 ±0.1 mm, an actuation force of 160 ±50 gf, and a minimum return force of 40 gf.
No product available!
MiniZed™ is a Zynq 7Z007S single-core development board. With the advent of the latest cost-optimized portfolio from Xilinx, this board targets entry-level Zynq developers with a low-cost prototyping platform.
No product available!
Pocket-sized computer that lets you get creative with digital technology. You can code, customize and control your micro:bit from anywhere! Use your micro:bit for all sorts of unique creations, from robots to musical instruments and more. SparkFun DEV-14336
No product available!
Dominique Guinard, Vlad Trifa
No product available!
No product available!
This kit comes with AlphaBot robotic platform (line tracking, obstacle avoidance, speed measuring, IR control), and a camera (with servo and 2 DOF pan head)
No product available!
DFRobot\'s Gravity Genuino (Arduino) 101 Starter Kit is an absolute beginner kit to get started with Arduino/Genuino 101. It comes with 11 projects with easy to follow tutorials. The Gravity interface (Plug&Play) provides the kit a fantastic user experience while keeping the great expandability. It is an excellent kit for STEM and Maker education. DFRobot KIT0113
No product available!
No product available!
PCB with programmed system for 4-channel thermostat with alarm. AVT5589 A +
No product available!
AVT kit for self-assembly of a 4-channel thermostat with alarm. AVT5589 B
No product available!
19:1 Metal Gearmotor 37Dx52L mm with 64 CPR Encoder