.png)
- New
zł5,202.44 tax excl.
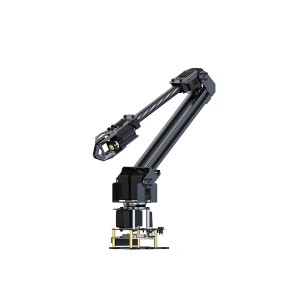
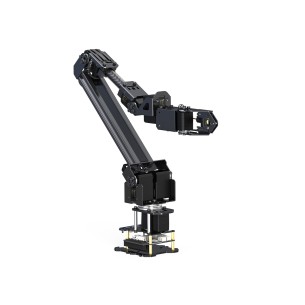
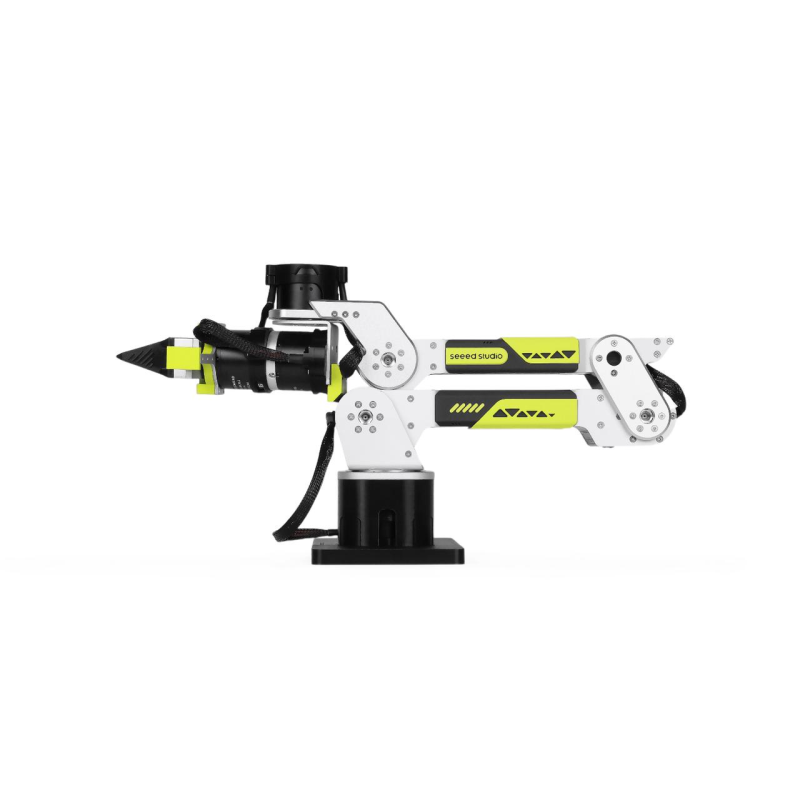
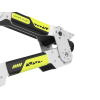
Seeed Studio reBot Arm B601-DM robotic arm with 6 degrees of freedom and an additional gripper axis, designed for robotics research, teleoperation, and artificial intelligence development. It offers a rated payload of 1.5 kg, a reach of up to 767 mm, and positioning repeatability of ±0.2 mm. The arm uses seven Damiao actuators and supports ROS1/2, LeRobot, Isaac Sim, and Python. Open-source documentation includes CAD models, bills of materials (BOM), SDKs, and educational resources. The robotic arm is supplied pre-assembled with a gripper, but without a power supply or mounting G-clamp. Seeed Studio 100065783
Seeed Studio 100065783 reBot Arm B601-DM robotic arm designed for robotics education, control algorithm development, and research into artificial intelligence for physical systems (Physical AI). The design offers 6 degrees of freedom and an additional gripper axis, a rated payload of 1.5 kg, and positioning repeatability of ±0.2 mm. The maximum reach with the gripper is 767 mm, allowing manipulation tasks to be performed in laboratory and research environments. The arm is supplied pre-assembled, reducing the mechanical assembly work required before configuration and testing.
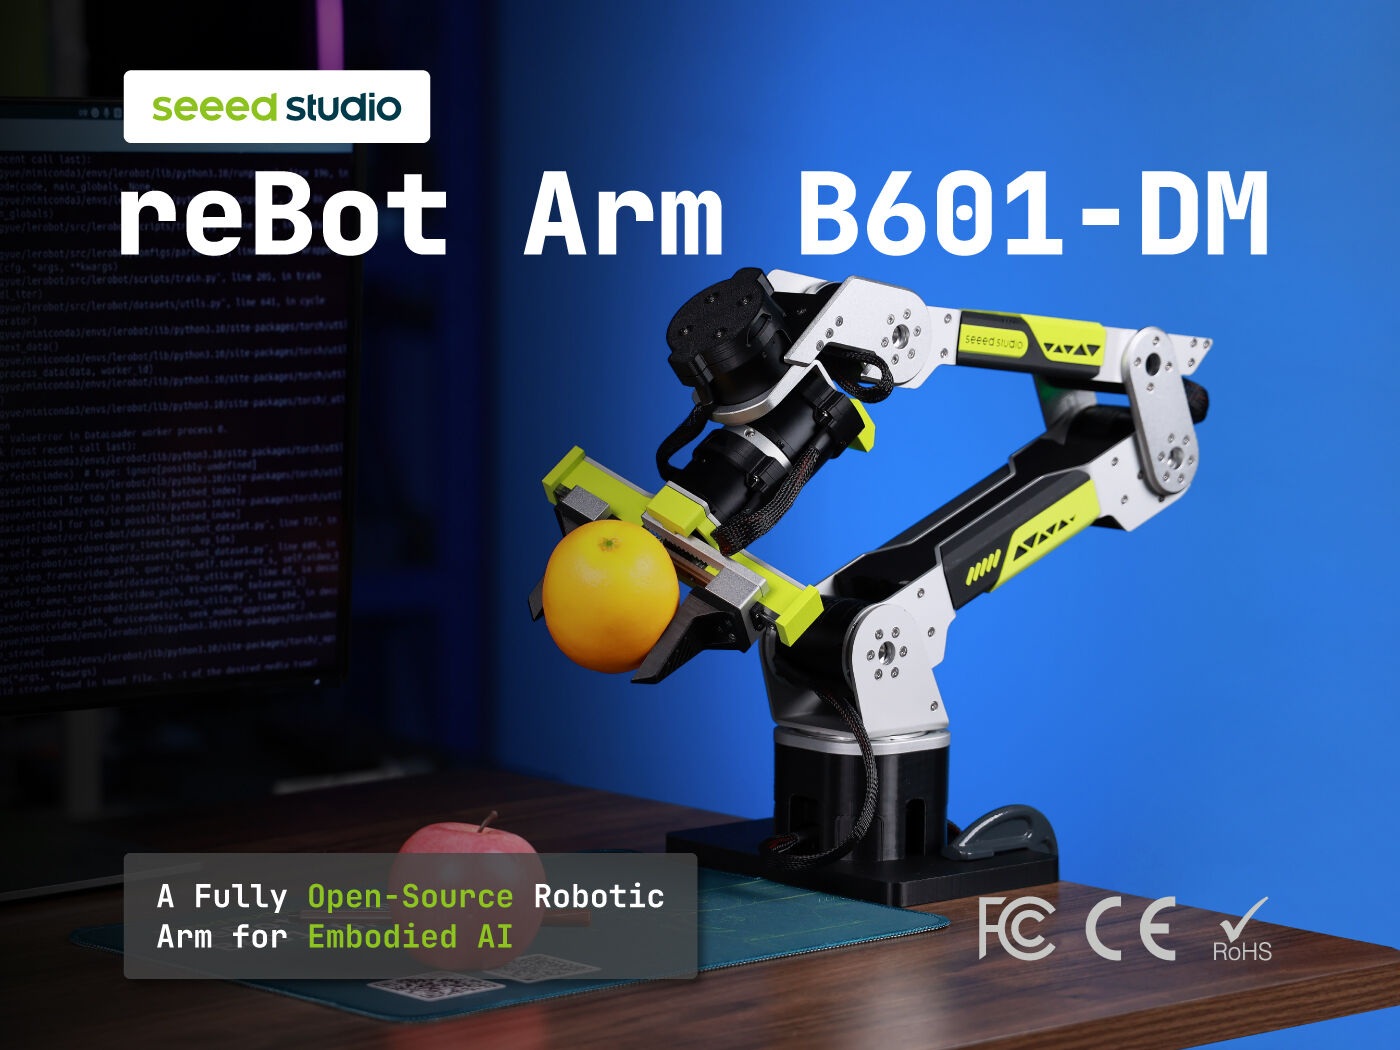
The reBot Arm B601-DM is suitable for teleoperation, training data collection, and robot learning through demonstration. When combined with the compatible Star Arm 102 leader arm, it can replicate the operator's movements and record data used to train control models. Integration with Hugging Face LeRobot supports the development of imitation learning algorithms and the validation of learned control policies on physical hardware.
The arm can also be used to build test stations for grasping, transferring, and sorting objects, motion planning, and testing vision systems. In laboratories and educational projects, it supports research into the automation of manipulation tasks and robot control under changing conditions.
SenseCraft Robotics provides tools for device configuration, calibration, teleoperation, and cloud-based AI model training. It also enables developers to validate trained algorithms on a local robotic platform, supporting the development and evaluation of robotics and Physical AI solutions.
The open-source hardware and software architecture allows developers to modify the manipulator's mechanical design and create custom robotics solutions. The manufacturer provides CAD models, bills of materials (BOM), technical documentation, SDK libraries, and control algorithm resources. The reBot-DevArm GitHub repository provides access to project resources. Support for ROS1, ROS2, MoveIt, LeRobot, Isaac Sim, Pinocchio, and Python enables integration of simulation, motion planning, and physical robot control.
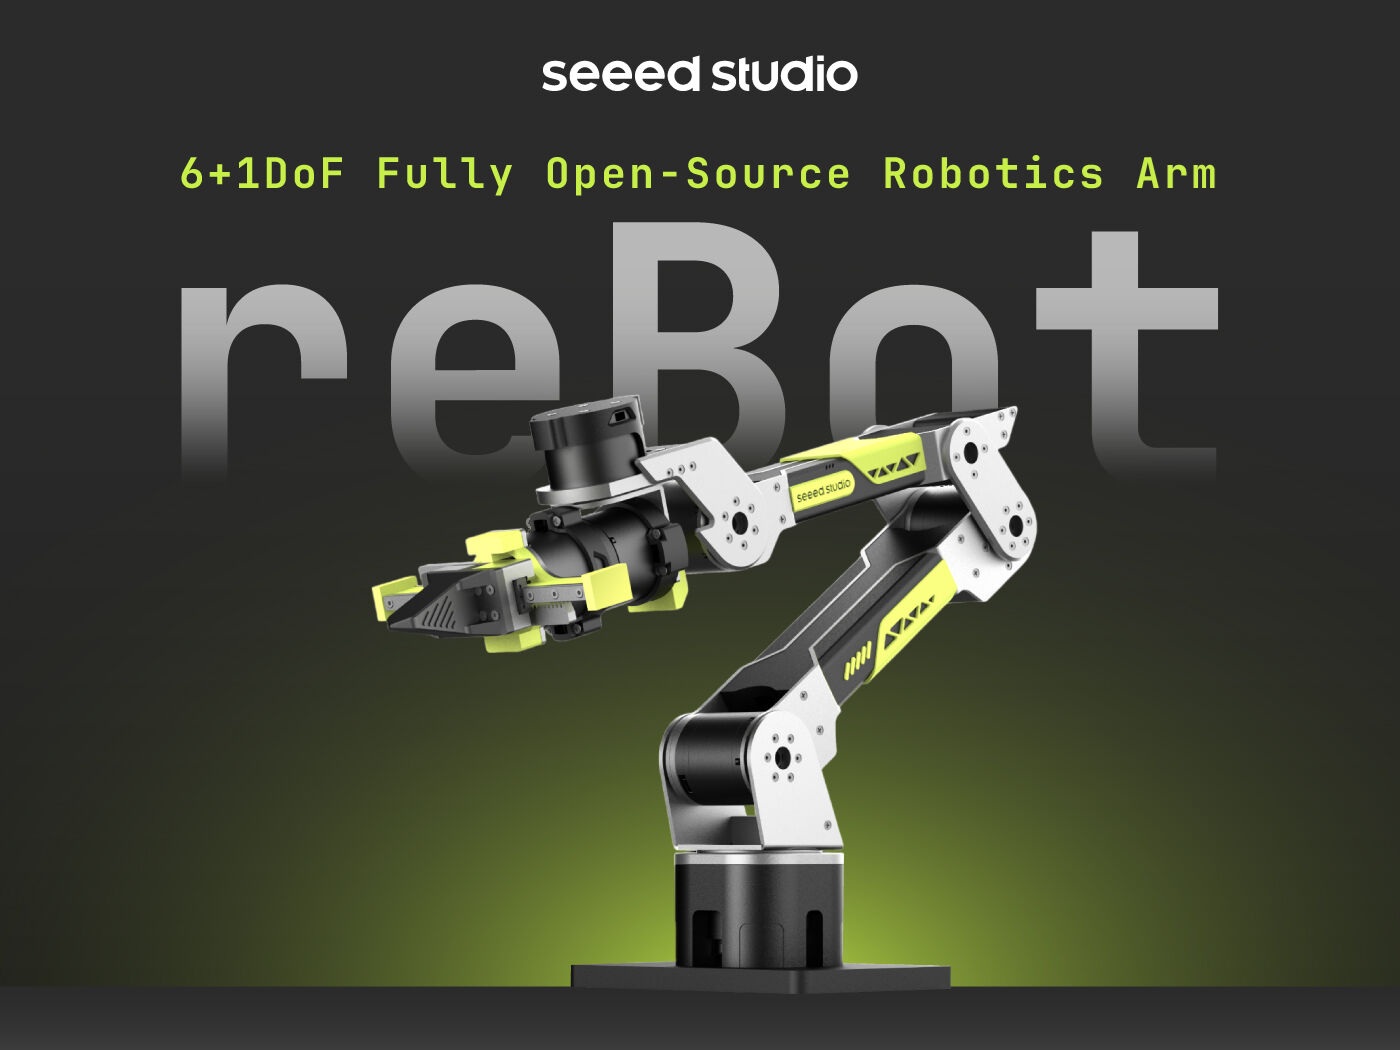
The drive system uses seven Damiao actuators: three DM-J4340P-2EC units and four DM-J4310-2EC units, controlling the six arm joints and the gripper. The first joint has a range of motion of ±150°, the second and third joints operate from -220° to 0°, and joints J4, J5, and J6 each have a range of ±90°. The gripper operates within a range of -325° to 0°. The reach without the gripper is 607 mm, increasing to 767 mm with the gripper. The manufacturer recommends operating at the rated payload within approximately 70% of the maximum reach. The robotic arm weighs approximately 4.7 kg and has a specified operating temperature range of -20°C to 50°C.
The manipulator requires a 24 V DC / 10 A power supply. Communication with a computer is provided through the included DAMIAO USB-CAN interface board. The kit also includes an XT30 2+2 power distribution board and a USB cable. Compatibility with ROS1, ROS2, and simulation environments enables the development of custom control software, testing of motion planning algorithms, and experiments involving robot learning. The available hardware documentation facilitates design analysis and integration with additional components of a robotics research workstation.
The Seeed Studio 100065783 reBot Arm B601-DM Without Power Supply version is supplied without a power supply or G-clamp. Both accessories must be purchased separately to ensure proper power delivery and secure mounting of the manipulator. Teleoperation using a leader arm additionally requires a compatible Star Arm 102 and its dedicated 12 V / 2 A power adapter. The kit includes a pre-assembled robotic arm with a gripper, a USB-CAN interface board, a power distribution board, a USB cable, a hex key wrench set, and a mouse pad.
Manufacturer
Responsible person
Empower your Romi robot to manipulate its surroundings with this robotic arm accessory kit! The kit contains everything you need to build the arm, including a micro gripper and three servos—one for controlling the height of the arm, one for controlling the tilt of the gripper, and one for actuating the gripper paddles themselves.
No product available!
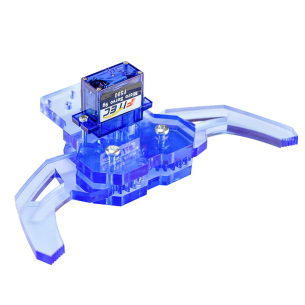
A small size gripper driven by a servomotor with a movement range of 32 mm. It contains a special micro servo with an additional wire that gives access to its feedback, so you can track the actual position of the gripper blades. Polol 3551
No product available!
A set for self-assembly of a robotic arm with four degrees of freedom (4DOF) equipped with MG90S servomechisms. The arm at the end has a small gripper which allows you to catch and carry small objects. The handle is controlled using a plate compatible with Arduino Uno or a module with potentiometers.
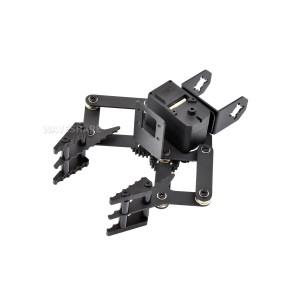
A robotic gripper based on the SG92R servo. It has an opening and closing angle of 90° and mounting holes compatible with Lego. M5Stack U102
Four degrees of freedom (4DOF) robotic arm assembly kit. The robotic arm was based on servos and is controlled wirelessly using a Raspberry Pi. Waveshare Robot Arm for Pi (for Europe)
A 5 DoF robotic arm built with servos and ESP32. It can be controlled wirelessly via WiFi and web browser or USB interface. Waveshare RoArm-M1 (EU)
No product available!
A robotic arm with four degrees of freedom (4 DoF) based on servomechanisms and a controller with an ESP32 module. It can be controlled wirelessly via WiFi and a web browser or USB interface. Waveshare RoArm-M2-S (EU)
No product available!
A new version of the popular Kitronik Klaw gripper, perfect for robotic and buggy projects. Compatible with MOVE Mk1 and Mk2, it enables precise gripping of objects using a servo mechanism, ensuring easy assembly and wide range of applications in robotics. Kitronik 25104
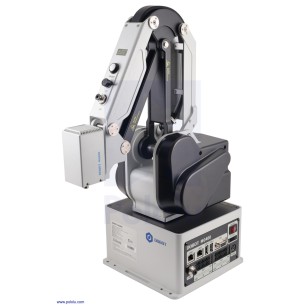
A compact, 4-axis collaborative robot with a repeatability of ±0.05 mm, designed for precise automation tasks at a low cost. It offers a 44 cm reach, a payload of up to 500 g, and intuitive features such as collision detection and drag-to-teach. With extensive I/O interfaces (Ethernet, USB, digital I/O, pneumatics) and a compact design, it is ideal for assembly, packaging, laboratory maintenance, and education. The Pololu 5400
No product available!
The RoArm-M2-Pro (EU) robotic arm provides four degrees of freedom, high control precision, and great expansion flexibility thanks to its open architecture based on ESP32. The Pro version, equipped with fully metal ST3235 servomechanisms, offers increased durability and accuracy of repeatable movements. Designed for educational, research and development, and prototyping applications, the product enables handling of various scenarios using mobile platforms, ROS2 systems, and 3D visualization. Thanks to extensive documentation and open resources, the arm can serve as a foundation for advanced projects in the field of automation and robotics.
No product available!
Gripper-A Waveshare 30385 is a solid and cost-effective choice for robotic arm builders, offering full closed-loop control and servo protection features. Thanks to its universal design, adjustable jaws, and camera integration capability, it is suitable for educational, laboratory, and semi-industrial robotic manipulation projects.
No product available!
Gripper-B Waveshare 30386 with CF35-12 servo provides advanced gripping functionality for robotic arms through precise force control, feedback, and real-time protection. The aluminum alloy and stainless steel housing, along with adjustable grip and expandability for vision systems, make it an ideal component for industrial, research, and educational applications in robotics.
No product available!
RoArm-M3-S (EU) is a versatile robotic arm, ideal for educators, makers, and researchers. With a wide range of control options, AI support, and comprehensive documentation, it enables quick deployment in advanced educational, prototyping, and experimental projects. The version with an EU power adapter is ready to use right out of the box.
No product available!
RoArm-M3-Pro (EU) is a fully functional robotic arm with advanced ESP32-based control, ready for integration with AI projects, ROS2, and educational environments. It offers a rich set of features for control, algorithm development, and physical manipulation, and comes with an EU power adapter for immediate use in European settings.
No product available!
An improved version of the educational robotic arm, designed for imitation learning and integration with the LeRobot and Hugging Face platforms. The kit includes servo motors, adapters and cables, offering a ready-made solution for rapid prototyping of AI systems in a real environment. Improved mechanisms and support for Nvidia Orin NX computers make it an ideal tool for research, education and reinforced learning experiments. Seeed Studio 114993667
RoArm-M3-Pro-AI-Kit is an open-source AI-grade robotic arm kit, ready for integration with Jetson Orin platforms or PCs, supporting advanced control algorithms and machine learning. With its reinforced construction and precise control, it is ideal for educational, R&D, and mobile or industrial robotics applications.
No product available!
Seeed Studio reBot Arm B601-DM robotic arm with 6 degrees of freedom and an additional gripper axis, designed for robotics research, teleoperation, and artificial intelligence development. It offers a rated payload of 1.5 kg, a reach of up to 767 mm, and positioning repeatability of ±0.2 mm. The arm uses seven Damiao actuators and supports ROS1/2, LeRobot, Isaac Sim, and Python. Open-source documentation includes CAD models, bills of materials (BOM), SDKs, and educational resources. The robotic arm is supplied pre-assembled with a gripper, but without a power supply or mounting G-clamp. Seeed Studio 100065783