.png)


zł581.52 tax excl.
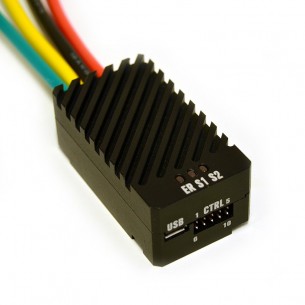
The RoboClaw Solo motor controllers from Basicmicro (formerly Ion Motion Control) can control a single brushed DC motor using USB serial, TTL serial, RC, or analog inputs. Pololu 3291
This version can supply a continuous 60 A (100 A peak) and operates up to 34 V.
The RoboClaws from Basicmicro (formerly Ion Motion Control) are a family of efficient, versatile, synchronous regenerative motor controllers. They can supply brushed DC motors with 7.5 A, 15 A, 30 A, 45 A, 60 A, or 120 A continuous (depending on the model) at voltages from 6 V to 34 V or 10.5 V to 60 V (also depending on the model), and they allow for peak currents well above the maximum continuous ratings. The “Solo” versions feature a single motor control channel while the dual versions (denoted by a “2x” in their names) offer two channels for controlling a pair of motors.
| Solo 30A | Solo 60A | 2x7A | 2x15A | 2x30A | 2x45A ST 2x45A | 2x60A | 2x60AHV | 2x160A | ||||||
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Motor channels: | 1 | 2 | 2 | |||||||||||
| Operating voltage: | 6 V to 34 V | 6 V to 34 V | 10.5 V to 60 V | |||||||||||
| Continuous output current: | 30 A | 60 A | 7.5 A | 15 A | 30 A | 45 A | 60 A | 60 A | 120 A | |||||
| Peak output current: | 60 A | 120 A | 15 A | 30 A | 60 A | 60 A | 120 A | 120 A | 160 A | |||||
| 5V BEC(1) max current: | 1.2 A | 1.2 A (V5B or later) | 3 A | 3 A | ||||||||||
| Size: | 60 × 32.5 × 23.5 mm | 48 × 42 × 17 mm | 74 × 52 × 17 mm | 100 × 86 × 30 mm | 100 × 86 × 30 mm | 212 × 126 × 50 mm | ||||||||
| Weight: | 130 g | 18 g | 60 g | 295 g | 295 g | 1630 g | ||||||||
1 Battery Eliminator Circuit
The RoboClaws have a USB interface that acts as a virtual serial (COM) port, allowing it to be controlled directly from a computer, and they feature built-in commands for controlling acceleration, deceleration, distance, speed, current sense, voltage limits and more. Several other interface modes are supported by the RoboClaw as well: it can be controlled via TTL serial for use with embedded systems, RC hobby servo pulses for use as an RC-controlled electronic speed control (ESC), or analog voltages for use with potentiometers or analog joysticks.
RoboClaw automatically supports 3.3V or 5V logic levels, travel limit switches, home switches, emergency stop switches, power supplies, braking systems and contactors. Power supplies can be used by enabling the built in voltage clamping control feature. A built-in switching mode BEC supplies 5VDC at up to 1.2 A or 3 A (depending on controller model) for powering user devices.
The RoboClaws can be operated without feedback for open-loop speed control, or they can be used with a variety of feedback types for closed-loop speed or position control. Quadrature encoders with up to 19.6 million pulses per second are supported and can be auto tuned using Ion Studio, which is a free downloadable application. In addition, a wide range of sensor inputs such as potentiometers and absolute encoders are supported. RoboClaw’s closed loop functionality creates absolute control over speed and direction regardless of load changes.
RoboClaw incorporates several protection features including temperature, current, over voltage and under voltage limits. Several user definable settings such as maximum current limit, maximum and minimum battery voltages are provided for more refined control.
| Motor channels: | 1 |
|---|---|
| Control interface: | USB; non-inverted TTL serial (2-way); RC servo pulses; analog voltage1 |
| Minimum operating voltage: | 6 V |
| Maximum operating voltage: | 34 V |
| Continuous output current per channel: | 60 A |
| Peak output current per channel: | 100 A |
| Size: | 60 × 32.5 × 23.5 mm |
|---|---|
| Weight: | 130 g |
Data sheet
Manufacturer
Responsible person
The RoboClaw Solo motor controllers from Basicmicro (formerly Ion Motion Control) can control a single brushed DC motor using USB serial, TTL serial, RC, or analog inputs. An integrated quadrature decoder make it easy to create a closed-loop speed control system.
A two-channel DC motor controller with a UART TTL interface. It is powered from 1.8 V to 22 V and can deliver up to 1.6 A per motor. Board with connectors. Pololu 5080
A two-channel DC motor controller with a I2C interface. It is powered from 1.8 V to 22 V and can deliver up to 1.6 A per motor. Board with connectors for assembly. Pololu 5079
A two-channel DC motor controller with an I2C interface. It is powered from 1.8 V to 22 V and can deliver up to 1.6 A per motor. Board with soldered connectors. Pololu 5078
A single-channel DC motor controller with a UART TTL interface. It is powered from 1.8 V to 22 V and can deliver up to 1.8 A of current. Board with connectors for assembly. Pololu 5077
A single-channel DC motor controller with a UART TTL interface. It is powered from 1.8 V to 22 V and can deliver up to 1.8 A of current. Board with soldered connectors. Pololu 5076
A single-channel DC motor controller with an I2C interface. It is powered from 1.8 V to 22 V and can deliver up to 1.8 A of current. Board with connectors for assembly. Pololu 5075
A single-channel DC motor controller with an I2C interface. It is powered from 1.8 V to 22 V and can deliver up to 1.8 A of current. Board with soldered connectors. Pololu 5074
2-channel brush motor controller module with PWM signal mixing function. It allows you to control two DC motors with a current consumption of up to 5 A per channel
3-channel brush motor controller module with PWM signal mixing function. It allows you to control three DC motors with a current consumption of up to 15 A per channel
3-channel brush motor controller module with PWM signal mixing function. It allows you to control three DC motors with a current consumption of up to 3 A per channel
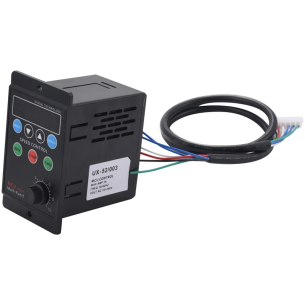
The UX-52 panel brush motor speed controller is a versatile device with speed adjustment from 90 to 1400 rpm. It offers precise control of motors with an input voltage of 220VAC, featuring a solid construction and a convenient digital display.
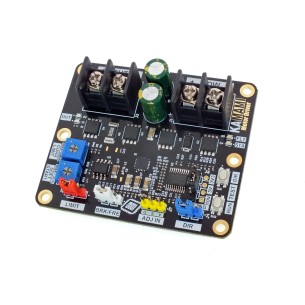
KAmod Motor Driver is an advanced DC motor controller powered by 6-30 V, enabling power regulation using the PWM method and control of the direction of rotation, compatible with analog and PWM signals from various sources, equipped with overload and thermal protections and soft start and stop functions
The dual-channel KAmod Motor Driver TB6612FNG with MOSFET H-bridges enables precise control of DC and stepper motors with PWM frequency up to 100 kHz. The compact design, wide voltage range, and protections make the module suitable for mobile projects, robotics, and automation.
This L298N module allows independent control of two DC motors or one stepper motor, ideal for robotics and DIY projects. It supports power supplies from 7V to 35V and has a built-in 5V regulator that can power additional circuits. Control is performed via the ENA, ENB, and IN1–IN4 pins, allowing for adjustable rotational direction and speed. The module is equipped with protection diodes and filter capacitors for stable and reliable operation.
An H-bridge capable of controlling one DC motor in both directions or two unidirectional motors at voltages from 4.5 to 44 V and continuous current up to 1.1 A. The module offers three operating modes (PH/EN, IN/IN, half-bridge), built-in current limiting and measurement, and protection against overheating, overload, undervoltage, and reverse polarity. Its compact design, flexible logic power supply (1.8–5.5 V), and simple control make it ideal for robotics, automation, and hobby projects. Pololu 4972
An H-bridge capable of controlling one DC motor in both directions or two unidirectional motors at voltages from 4.5 to 44 V and continuous currents up to 1.3 A. The module offers three operating modes (PH/EN, IN/IN, half-bridge), built-in current limiting and measurement, and protection against overheating, overload, undervoltage, and reverse polarity. Its compact design, flexible logic power supply (1.8–5.5 V), and simple control make it ideal for robotics, automation, and hobby projects. Pololu 4971
The RoboClaw Solo motor controllers from Basicmicro (formerly Ion Motion Control) can control a single brushed DC motor using USB serial, TTL serial, RC, or analog inputs. Pololu 3291