
.png)
















Category: MECHANICS
Mechanics - Structural Components, Drives and Accessories
The Mechanics category includes components for building drive systems, mechanical structures, robots, machines, electronic devices, and automation systems. The range includes motors, servos, linear actuators, wheels, tracks, robot chassis, mounting components, enclosures, grippers, electromagnets, solenoid valves, and pumps. Available components can be used to generate motion, transfer mechanical power, build actuating mechanisms, and construct and protect complete devices.
Subcategories
There are 2276 products.
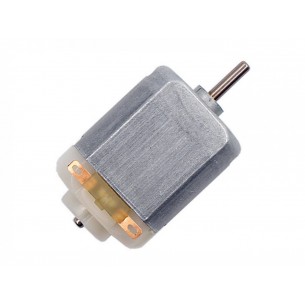
Mini DC motor with permanent magnets with a rotation speed of up to 18,000 rpm. In a housing 130 with a 2 mm shaft

Vibration motor 10 × 3.3 mm powered by 3–5 V DC generates stable vibrations at a speed of about 12,000 RPM. Thanks to its compact dimensions and low power requirements, it is used in mobile devices, indicators, and information systems.
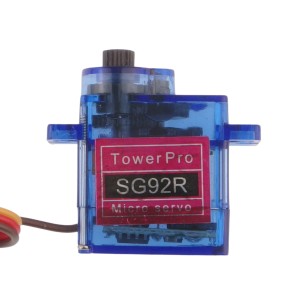
Micro digital servo with carbon fiber gearbox. It has a range of motion of 180°. TowerPro SG92R
Permanent cylindrical neodymium magnet with a diameter of 12 mm and a height of 1,5 mm. Set of 10 pcs
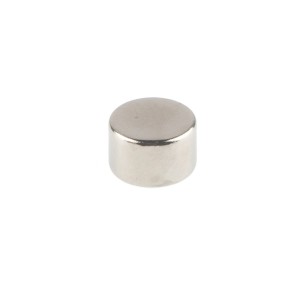
Permanent cylindrical neodymium magnet with a diameter of 8 mm and a height of 5 mm. Set of 10 pcs
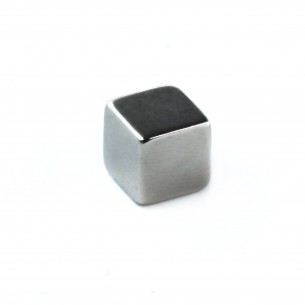
Neodymium rectangular magnet with dimensions of 9x9mm a and a height of 9 mm.
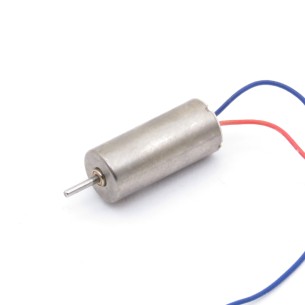
DC motor with hollow dome. Features a compact and lightweight design, making it ideal for applications requiring small size and low weight
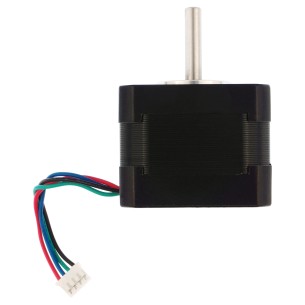
NEMA 17 stepper motor with a resolution of 200 steps per revolution. It is powered by 5.3 V and provides a torque of 27 N-cm. It has a "D"-shaped shaft with a diameter of 5 mm, which facilitates installation and ensures a secure connection with other elements of the system. QSH4218-35-10-027
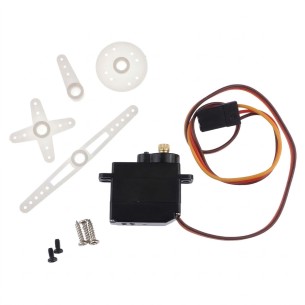
Micro analog servo with metal gear, controlled by standard PWM (1500–1900 µs), with a range of approx. 145°, power supply 4.8–6 V (at 6 V: 0.10 s/60° and 2 kg cm; at 4.8 V: 0.12 s/60° and 1.6 kg cm), with 3-pin JR/Futaba cable, dimensions 23×11.5×24 mm and weight 12 g; complete with control rods and mounting elements, ideal for small flying models
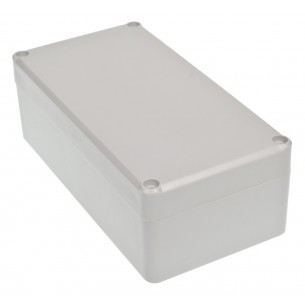
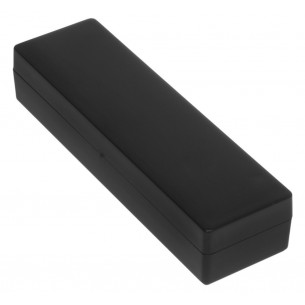
Hermetic enclosure Z58 lightgray with gasket PS
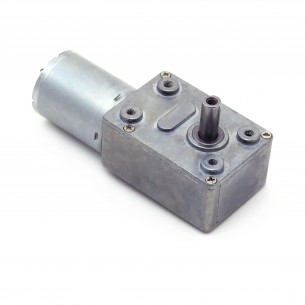
Metal Worm Gear Motor, 30 RPM Rotation Speed, 12V Working Voltage. JGY370-29
Motors, Servos and Actuators
Motors, servos, and actuators provide motion for robots, machines, and actuating mechanisms. Depending on the system design, DC motors, BLDC motors, stepper motors, servos, and linear actuators can be selected according to supply voltage, speed, torque, travel range, and control method.
Wheels, Tracks and Robot Chassis
Drive system components enable the construction of mobile platforms and robots designed to move across different surfaces. Wheels, tracks, ball casters, and robot chassis can be used to assemble mobile platforms and match the mechanical structure to the propulsion system, required load capacity, and intended movement characteristics.
Mounting Components and Brackets
Mounting components provide mechanical connections between parts and support the construction of complete devices. Brackets, mounts, and other structural accessories can be used to install motors, sensors, electronic boards, and additional components in robotics, automation, and prototyping projects.
Grippers, Electromagnets and Actuating Components
Grippers and electromagnets can be used to build mechanisms for gripping, holding, and moving objects. Combined with suitable drives and control systems, they can be integrated into robotic manipulators, automation mechanisms, and prototype systems.
Pumps and Solenoid Valves
Pumps and solenoid valves are used in systems requiring the transfer or control of liquids and gases. Parameters such as supply voltage, flow rate, pressure, connection diameter, and compatible medium help determine suitability for pneumatic, hydraulic, dosing, and cooling systems.
Enclosures and Structural Accessories
Enclosures protect electronics and other device components against mechanical damage and environmental conditions within the protection capabilities of a particular design. Enclosure accessories and mounting components facilitate the installation of circuit boards, cables, connectors, and other components inside a device.
Selecting Mechanical Components
Mechanical components should be selected according to dimensions, mounting method, material, load requirements, and mechanical and electrical compatibility. For drive systems, additional parameters such as torque, speed, supply voltage, and the method of transferring mechanical power should also be considered.