.png)

















zł635.18 tax excl.
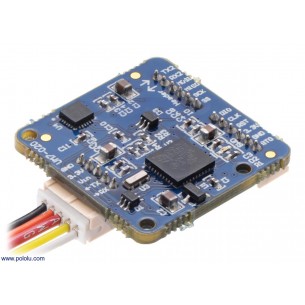
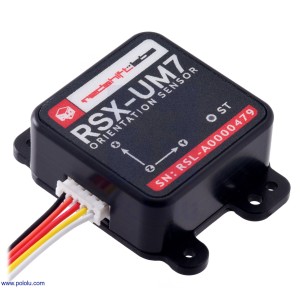
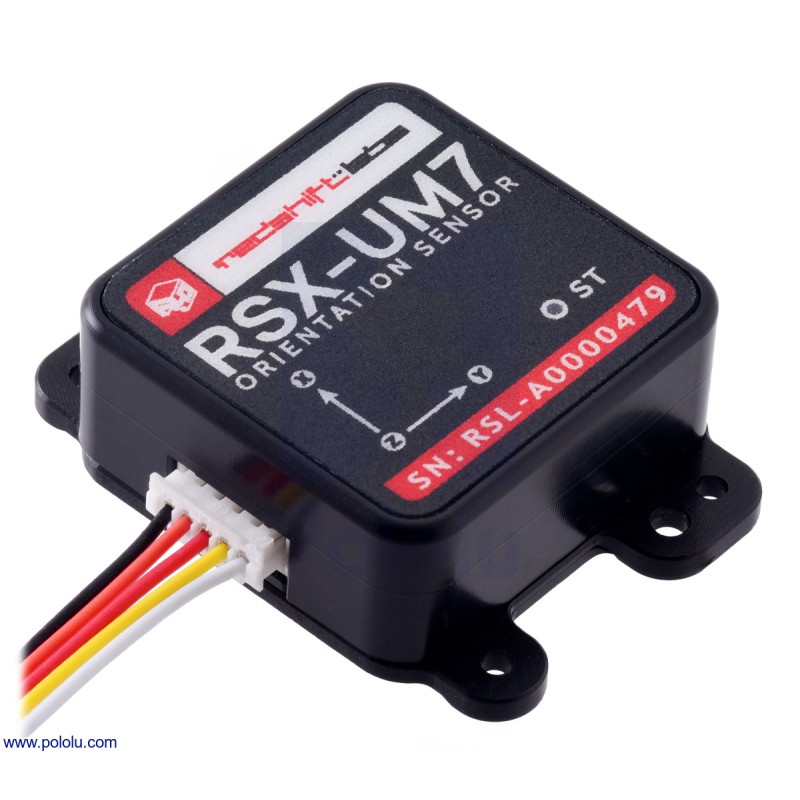
The UM7 orientation sensor from Redshift Labs is an Attitude and Heading Reference System (AHRS) that contains a three-axis accelerometer, rate gyro, and magnetometer. It combines this data using an Extended Kalman Filter to produce attitude and heading estimates.
Redshift Labs is now manufacturing and supporting the UM7-LT and UM7 orientation sensors (which were originally developed by CH Robotics). Some components have been updated on these versions of the sensors, and the UM7-LT now ships with a conformal coating, but the sensors should otherwise be functionally identical to the previous versions.
The UM7 orientation sensor is a third-generation Attitude and Heading Reference System (AHRS) from Redshift Labs that produces attitude and heading estimates from triaxial accelerometer, rate gyro, and magnetometer data. Unlike a typical inertial measurement unit (IMU), which only provides raw sensor readings, the UM7 features an onboard microcontroller that combines sensor data using a sophisticated Extended Kalman Filter (EKF) to generate orientation estimates 500 times a second.
Two versions of the UM7 are available: the UM7 orientation sensor, which includes an enclosure, and the UM7-LT, which does not. The two versions are functionally equivalent, and both include a cable.
The UM7 features a number of improvements over its predecessor, the UM6, including higher gyro bias stability and lower noise, a new communication architecture for improved flexibility, optional NMEA packet transmission, UTC time-synchronization with external GPS, and support for third-order temperature compensation on all sensors. It takes advantage of newer MEMS (micro-electro-mechanical systems) technology that allows it to offer better performance at a lower price.
Connections for power and TTL serial communication can be made to the UM7 through a polarized five-pin male connector on one side, which mates with an included cable assembly. A pair of six-pin expansion headers on the other side of the board provide additional connectivity options, including an alternative SPI interface and a secondary serial interface that can be connected to an external GPS module (like ourLS20031 GPS receiver). Additional cable assemblies for the expansion headers are not included.
You can use a general-purpose USB-to-TTL-serial adapter, such as our CP2104 carrier, to connect the UM7 to your computer. You can then use the Redshift Serial Interface (available in the “Resources” tab) to configure the sensor, and view and log data in real-time.
Product #2764 is the UM7 orientation sensor with an enclosure.
We carry several inertial measurement and orientation sensors. The table below compares their capabilities:
| Product Name | Sensors | Estimation | Other | ||||||
|---|---|---|---|---|---|---|---|---|---|
| Gyros (3x) | Accels (3x) | Mag (3x) | Altitude | Roll | Pitch | Yaw | Quaternion | Enclosure | |
| Pololu MinIMU-9 v5 |  |
|
|
||||||
| Pololu AltIMU-10 v5 | |
|
|
|
|||||
| Redshift Labs UM7-LT Orientation Sensor | |
|
|
|
|
|
|
||
| Redshift Labs UM7 Orientation Sensor | |
|
|
|
|
|
|
|
|
| Size: | 1.09″ × 1.12″ × 0.37″1 |
|---|---|
| Weight: | 7.5 g2 |
| Interface: | TTL serial, SPI |
|---|---|
| Minimum operating voltage: | 4 V |
| Maximum operating voltage: | 5.5 V |
| Maximum logic voltage: | 3.3 V3 |
| Axes: | pitch (x), roll (y), and yaw (z) |
| Measurement range: | ±2000°/s (gyro) ±8 g (accelerometer) ±12 gauss (magnetometer) |
| Supply current: | 50 mA |
| Case/enclosure: | Y |
Data sheet
Manufacturer
Responsible person
The UM7-LT orientation sensor from Redshift Labs is an Attitude and Heading Reference System (AHRS) that contains a three-axis accelerometer, rate gyro, and magnetometer. It combines this data using an Extended Kalman Filter to produce attitude and heading estimates. This LT version of the UM7 does not have an enclosure.
6DoF module with MPU6050 (3-axis accelerometer, 3-axis gyroscope) powered with 3-5V. I2C communication interface
No product available!
GY-801 is a 9DOF IMU module with L3G4200D, ADXL345, MMC5883MA and BMP180 systems. It allows you to measure the movement of the object and atmospheric pressure.
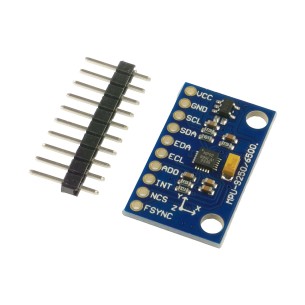
GY-9250 is a 9 Degrees of Freedom (9DoF) module with the InvenSense MPU-9250 chip. It has a built-in gyroscope, accelerometer and magnetometer.
Accelerometer and gyroscope module, allows measurement of acceleration in the range of +/- 16 G and angular velocity in the range up to +/- 2000 dps. modMPU6500 (GY-6500)
MEMS accelerometer, magnetometer and gyroscope on a single die with a high speed ARM Cortex-M0 based processor
The LSM6DS33 combines a digital 3-axis accelerometer and 3-axis gyroscope into a single package. The sensor provides six independent acceleration and rotation rate readings whose sensitivities can be set in the ranges of ±2 g to ±16 g and ±125°/s to ±2000°/s, available through I²C and SPI interfaces.
The Pololu MinIMU-9 v5 is an inertial measurement unit (IMU) that packs an LSM6DS33 3-axis gyro and 3-axis accelerometer and an LIS3MDL 3-axis magnetometer onto a tiny 0.8″ × 0.5″ board.
GY-9255 is a 9 Degrees of Freedom (9DoF) module with the InvenSense MPU-9255 chip. It has a built-in gyroscope, accelerometer and magnetometer
No product available!
The UM7-LT orientation sensor from Redshift Labs is an Attitude and Heading Reference System (AHRS) that contains a three-axis accelerometer, rate gyro, and magnetometer. It combines this data using an Extended Kalman Filter to produce attitude and heading estimates. This LT version of the UM7 does not have an enclosure.
The UM7 orientation sensor from Redshift Labs is an Attitude and Heading Reference System (AHRS) that contains a three-axis accelerometer, rate gyro, and magnetometer. It combines this data using an Extended Kalman Filter to produce attitude and heading estimates.
KAmodLSM303C is a module with the MEMS LSM303C chip from STMicroelectronics. The chip has a digital signal output (I2C or SPI bus) and allows measurement of accelerations and magnetic field values in three axes
KAmodLSM6DS3 is a module that allows measurement of acceleration and angular velocity values. It has a built-in voltage stabilizer and level translators on SDA / SCL lines, thanks to which it can be used in 2.5-5.5V voltage systems
Versatile 9DOF sensor with accelerometer, magnetometer and gyroscope, supporting I²C and SPI interfaces, enabling precise measurement of motion, orientation and temperature, with easy integration with Arduino and microcontrollers. Adafruit 3387
The GY-87 module is composed of a module with MPU6050, QMC5883L and BMP180 sensors, allowing the measurement of traffic in nine axes and the measurement of atmospheric pressure. The module has a built-in 3.3 V voltage stabilizer
No product available!
GY-86 10 Degrees of Freedom Flight Control Sensor Module with MPU6050, HMC5883L and MS5611 sensors on a single board. With the help of this module , you can read the values from its on-board 3 axis gyroscope , 3 axis accelerometer ,3 axis magnetic field and air pressure as well. The module has a built-in 3.3V voltage stabilizer. modGY-86
Sensor module for use in the area of virtual reality (VR). It was based on the BNO080 chip, which integrates the accelerometer, gyroscope and magnetometer with the ARM Cortex M0+ microcontroller. SparkFun SEN-14686
No product available!
The UM7 orientation sensor from Redshift Labs is an Attitude and Heading Reference System (AHRS) that contains a three-axis accelerometer, rate gyro, and magnetometer. It combines this data using an Extended Kalman Filter to produce attitude and heading estimates.