.png)
- New
zł93.94 tax excl.
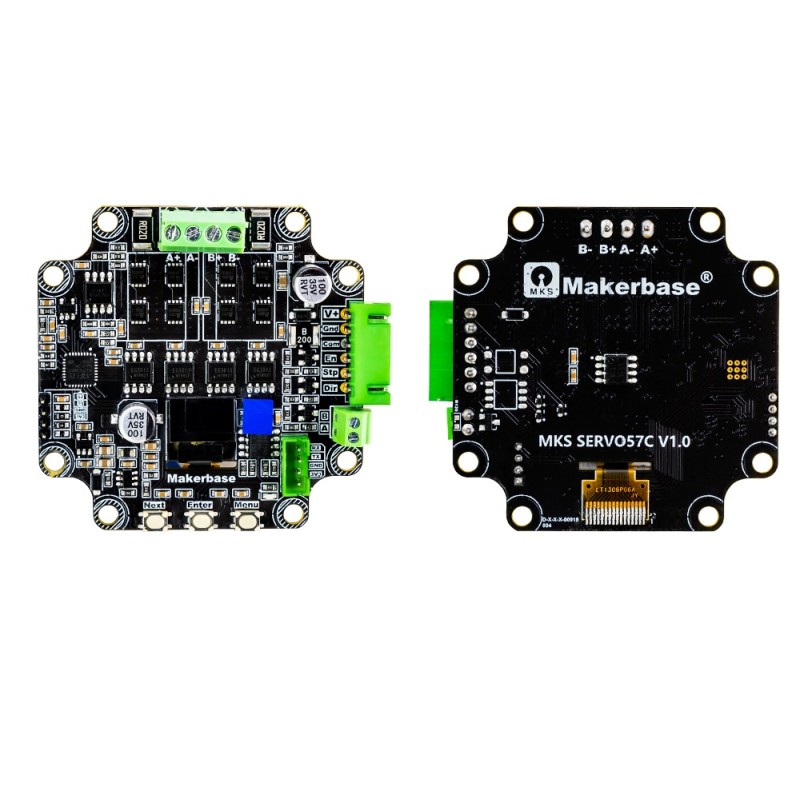
Makerbase MKS SERVO57C MB1 closed-loop stepper motor driver designed for NEMA 23 motors. Features a 32-bit AT32F421 microcontroller running at 120 MHz, a 14-bit magnetic encoder and a Field-Oriented Control (FOC) algorithm. Supports a 12 V to 24 V DC supply, an operating current range of 0 A to 5.2 A, STEP/DIR pulse control at frequencies up to 120 kHz, and UART TTL and RS485 communication. The kit includes the driver board, MKS APT adapter, two heatsinks and mounting hardware, without a motor. Makerbase MKS SERVO57C MB1
The MKS SERVO57C MB1 stepper motor driver from Makerbase is designed to control two-phase NEMA 23 stepper motors in closed-loop systems. The module features a 32-bit AT32F421 microcontroller with an ARM Cortex-M4 core running at 120 MHz and a 14-bit magnetic encoder for measuring the actual angular position of the motor shaft. The integrated Field-Oriented Control (FOC) algorithm adjusts motor operation based on encoder feedback, reducing the risk of missed steps and motor vibration. The driver is suitable for CNC machines, robotics, automation, 3D printers and positioning mechanisms requiring motor motion control.
The MKS SERVO57C MB1 operates with a supply voltage of 12 V to 24 V DC and supports an operating current range of 0 A to 5.2 A. The design uses AH30H80Q MOSFETs and a control system providing torque, speed and position regulation. The torque control loop operates at an update frequency of 20 kHz, while the speed and position control loops operate at 10 kHz. The manufacturer specifies a maximum rotational speed exceeding 3000 rpm. The driver supports configurable step subdivision from 1 to 256, with a default setting of 1/16 step. Internal interpolation up to 1/256 step helps improve motor motion smoothness at low rotational speeds.
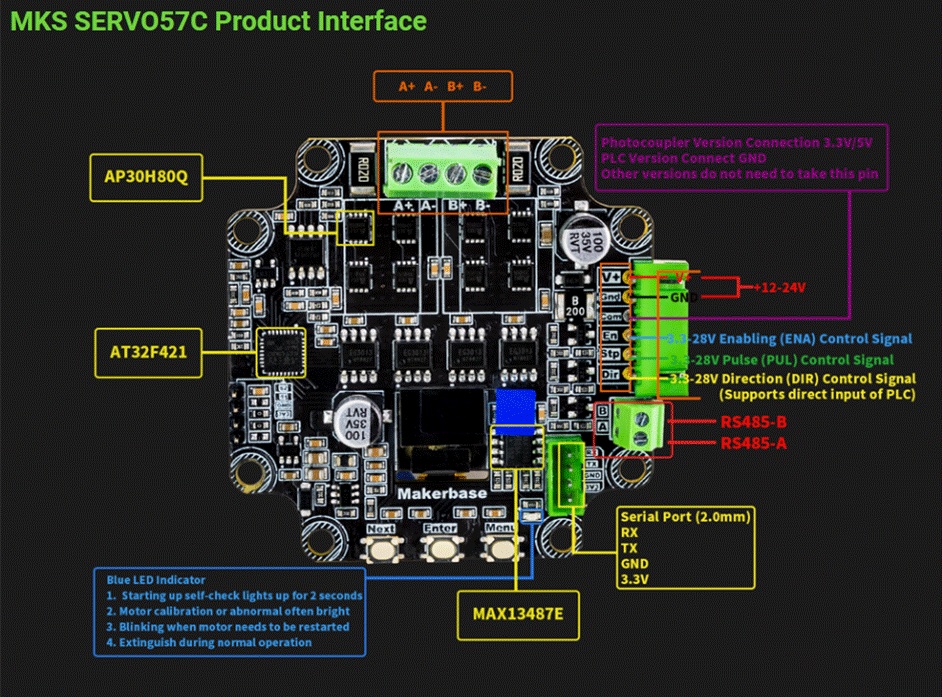
The module provides STEP/DIR pulse control inputs with a maximum signal frequency of 120 kHz. The driver accepts input signal voltage levels from 3.3 V to 24 V, allowing control signals to be received from motion controllers and PLCs. It supports open-loop operation, closed-loop current regulation, FOC control and serial communication mode. In feedback-based operating modes, the encoder provides information about the current rotor position, allowing the controller to adjust motor operation. The module also allows configuration of motor rotation direction, motor current, microstep resolution and stall protection.
The driver features USART (TTL) and RS485 communication interfaces for configuring operating parameters and controlling the motor from a host device. Serial communication supports transmission rates from 9600 to 256000 bit/s, while the RS485 bus allows addressing of up to 255 slave devices and supports a broadcast address. The RS485 communication circuit uses a MAX13487E transceiver. Makerbase provides the MKS SERVO57C CONTROL TOOL software for adjusting operating parameters, reading motor position, monitoring rotational speed and checking drive status. The driver also supports motor calibration and restoration of factory settings.
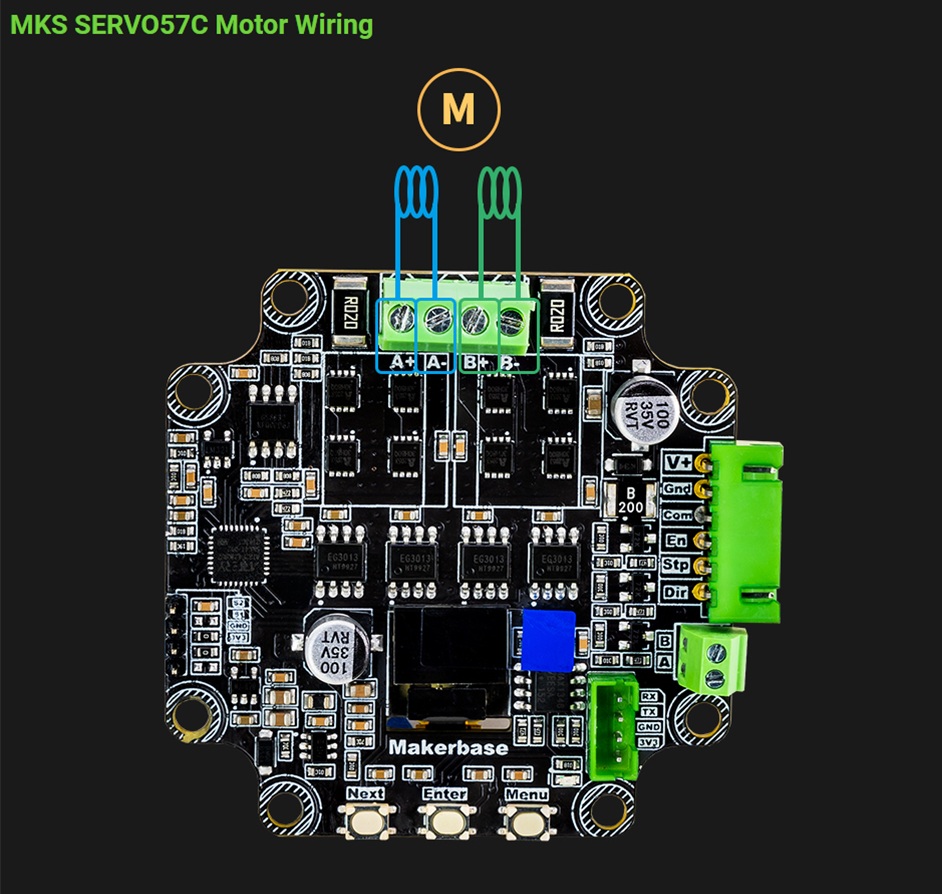
The MKS SERVO57C MB1 is designed for mounting on the rear of a NEMA 23 stepper motor, with the magnetic sensor aligned with a magnet attached to the motor shaft. The manufacturer recommends a distance of 0.5 mm to 3 mm between the magnet and sensor, with a maximum axis misalignment of 0.3 mm. The included MKS APT adapter board facilitates signal connections, while two 15 x 14.5 x 13 mm heatsinks help dissipate heat generated by the driver electronics. The kit also contains a 6 x 2.5 mm radial magnet, four M3 x 7 mm screws, ABS spacers, a hex key and a 60 cm 6-pin signal cable. The kit does not include a stepper motor. Before operation, the motor winding connections, driver configuration and alignment of the magnet with the encoder must be checked.
Data sheet
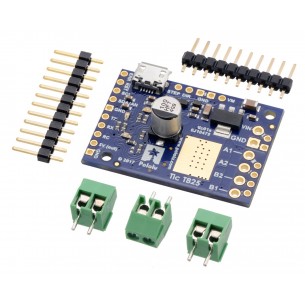
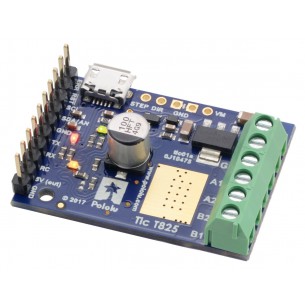
The Tic T825 USB Multi-Interface Stepper Motor Controller makes basic control of a stepper motor easy, with quick configuration over USB using our free software. The controller supports six control interfaces: USB, TTL serial, I²C, analog voltage (potentiometer), quadrature encoder, and hobby radio control (RC).
No product available!
The Tic T825 USB Multi-Interface Stepper Motor Controller makes basic control of a stepper motor easy, with quick configuration over USB using our free software. The controller supports six control interfaces: USB, TTL serial, I²C, analog voltage (potentiometer), quadrature encoder, and hobby radio control (RC).
No product available!
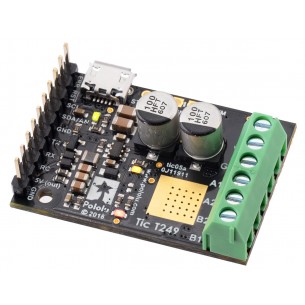
Stepper motor driver based on TB67S249FTG. It allows you to control a stepper motor with voltage from 10 to 47V, with a maximum current of 1.8A. The controller can be controlled using: USB, Serial TTL, I2C, RC (PWM modeling), analog input or quadrature encoder. Pololu 3138
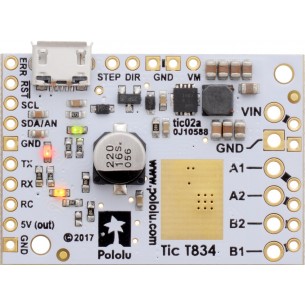
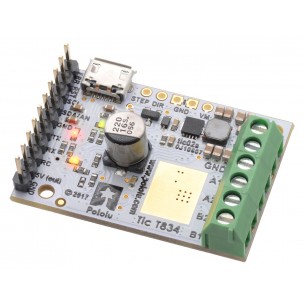
The Tic T834 USB Multi-Interface Stepper Motor Controller makes basic control of a stepper motor easy, with quick configuration over USB using our free software. The controller supports six control interfaces: USB, TTL serial, I²C, analog voltage (potentiometer), quadrature encoder, and hobby radio control (RC).
The Tic T834 USB Multi-Interface Stepper Motor Controller makes basic control of a stepper motor easy, with quick configuration over USB using our free software. The controller supports six control interfaces: USB, TTL serial, I²C, analog voltage (potentiometer), quadrature encoder, and hobby radio control (RC).
No product available!
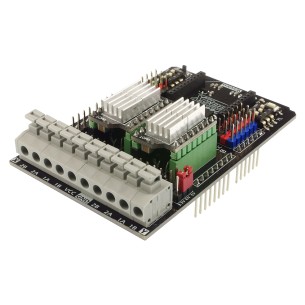
DRV8825 Stepper Motor Driver Module for Arduino. It allows you to control two drives, equipped with an XBee connector. DFRobot DRI0023
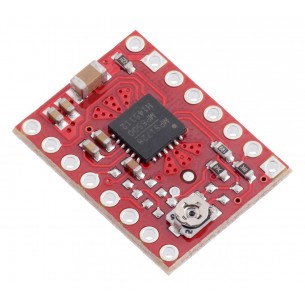
The stepper motor driver with the MP6500 system allows the bipolar motor to be supplied with current up to 1.5 A per phase, without the use of a heat sink. The system can be supplied with voltage in the range 4.5 ... 35 V. Pololu 2966
MP6500 Stepper Motor Driver Carrier, Digital Current Control
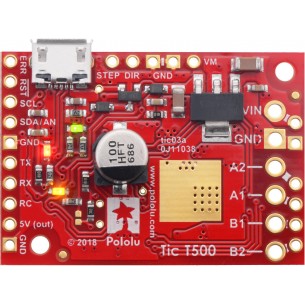
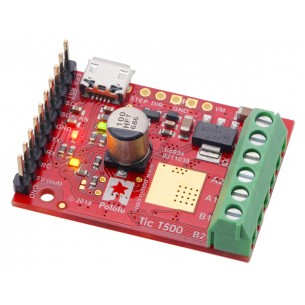
Tic T500 USB Multi-Interface Stepper Motor Controller
Tic T500 USB is a stepper motor driver based on the MP6500 chip. It allows you to control the stepper motor whose voltage on the coil is 4.5-35V, the maximum current per coil is up to 1.5A. The controller can be controlled by: USB, TTL, I2C, RC (PWM model) etc. Pololu 3134
TB67S279FTG stepper motor controller module supplied with 10 ... 47V voltage and 1.2A working current. The controller allows you to control the motor movement up to 7 different resolutions (up to 1/32 of a step). Pololu 2974
TB67S249FTG stepper motor driver module supplied with 10-47V voltage and working current of 1.7A. The controller allows you to control the motor movement up to 7 different resolutions (up to 1/32 of a step). Pololu 2973
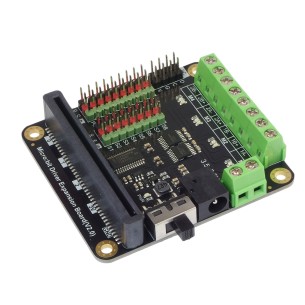
The expansion module is designed to work with micro:bit. It allows you to control 4 DC motors or two stepper motors and 8 servos. It communicates via the I2C interface. DFRobot DFR0548
TMC5130A-BOB enables convenient testing and integration of stepper motor control in applications requiring precise positioning and motion control. Integrated ramping functions, microstep interpolation, and encoder support make it an ideal choice for automation, robotics, and mechatronic systems.
TMC5072-BOB is a compact breakout board featuring the TMC5072 IC, designed for rapid prototyping of precision motion-control applications. High microstepping resolution, encoder support and a wide supply voltage range make it suitable for projects such as 3D printers, CNC axis controllers and robotic manipulators.
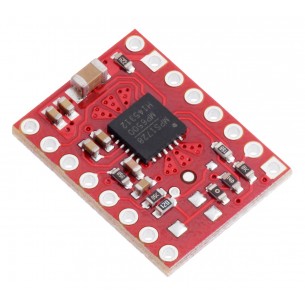
Stepper motor driver with MP6500 system with a potentiometer for current regulation. It allows the bipolar motor to be supplied with current up to 1.5A per phase without the use of a heat sink. Pololu 2967
No product available!
Makerbase MKS SERVO57C MB1 closed-loop stepper motor driver designed for NEMA 23 motors. Features a 32-bit AT32F421 microcontroller running at 120 MHz, a 14-bit magnetic encoder and a Field-Oriented Control (FOC) algorithm. Supports a 12 V to 24 V DC supply, an operating current range of 0 A to 5.2 A, STEP/DIR pulse control at frequencies up to 120 kHz, and UART TTL and RS485 communication. The kit includes the driver board, MKS APT adapter, two heatsinks and mounting hardware, without a motor. Makerbase MKS SERVO57C MB1