.png)
zł80.04 tax excl.
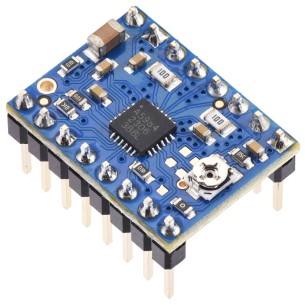
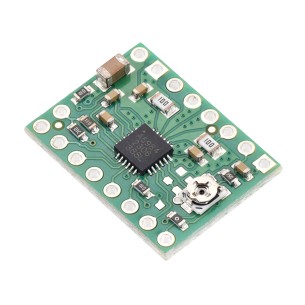
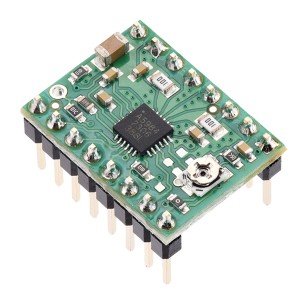
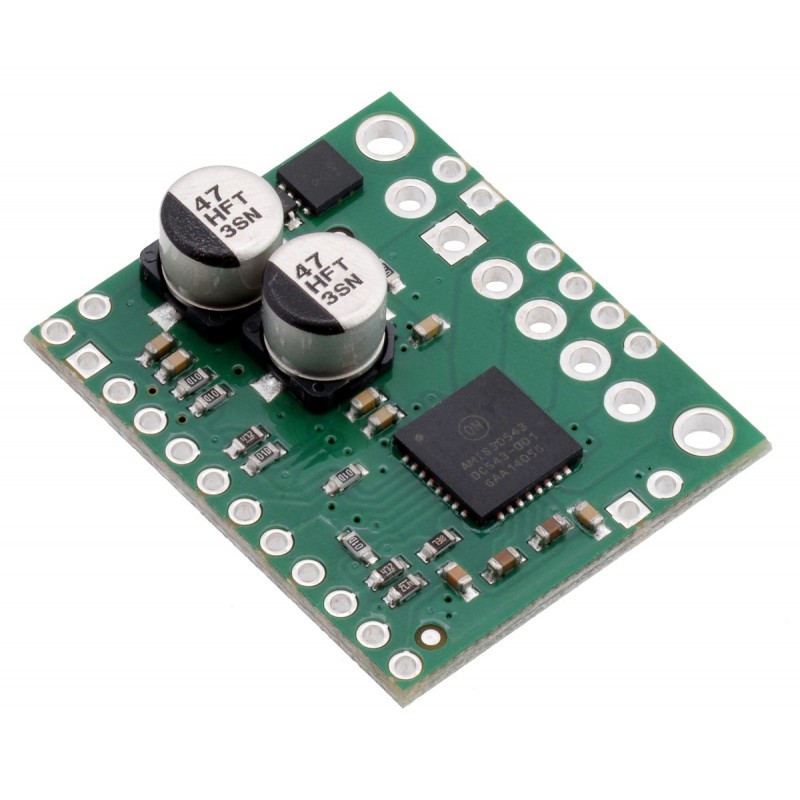
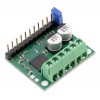
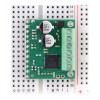
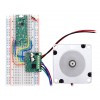
This is a breakout board for ON Semiconductor’s AMIS-30543 microstepping bipolar stepper motor driver, which features SPI-adjustable current limiting, 11 step modes (from full-step through 1/128-step), back-EMF feedback that can be used for stall detection or optional closed-loop control, and over-current and over-temperature protection.
This product is a carrier board or breakout board for ON Semiconductor’s AMIS-30543 Micro-Stepping Motor Driver. This stepper motor driver lets you control one bipolar stepper motor at up to 3 A output current per coil (see the Power Dissipation Considerations section below for more information). Here are some of the board’s key features:
Note: This driver needs to be enabled and configured through its SPI interface on power up, so your microcontroller must be capable of acting as an SPI master (either with an SPI peripheral or software SPI).
This product ships with all surface-mount components—including the AMIS-30543 driver IC—installed as shown in the product picture. However, soldering is required for assembly of the included through-hole parts. The following through-hole parts are included:
The 0.1″ male header can be broken or cut into smaller pieces as desired and soldered into the smaller through-holes. These headers are compatible with solderless breadboards, 0.1″ female connectors, and our premium and pre-crimped jumper wires. The terminal blocks can be soldered into the larger holes to allow for convenient temporary connections of unterminated power and stepper motor wires. You can also solder your motor leads and other connections directly to the board for the most compact installation.
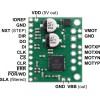
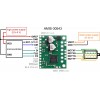
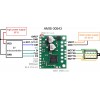
| PIN | Description |
|---|---|
| VMOT | Reverse-protected 6 V to 30 V board power supply connection. Note: Available VDD current is reduced for input voltages under 8 V, and sleep mode is not available for input voltages under 9 V. |
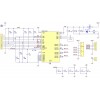
| VBB | This pin gives access to the motor power supply after the reverse-voltage protection MOSFET (see the board schematic below). It can be used to supply reverse-protected power to other components in the system. It is generally intended as an output, but it can also be used to supply board power. |
| GND | Ground connection points for the motor power supply and control ground reference. The control source and the motor driver must share a common ground. |
| MOTXP | Motor output: “positive” end of phase X coil. |
| MOTXN | Motor output: “negative” end of phase X coil. |
| MOTYP | Motor output: “positive” end of phase Y coil. |
| MOTYN | Motor output: “negative” end of phase Y coil. |
| VDD (5V OUT) | The board is powered by an internal 5V regulator, and this pin gives access to the regulated 5 V output. This can be used to supply the neighboring IOREF pin when using this board in 5V systems, and it can be used to power an external microcontroller. When VMOT is over 8 V, approximately 30 mA is available for external components; when VMOT is less than 8 V, the available current drops to less than 10 mA. |
| IOREF | All of the board signal outputs (except SLA) are open-drain outputs that are pulled up to IOREF, so this pin should be supplied with the logic voltage of the controlling system (e.g. 3.3V for use in 3.3V systems). For convenience, it can be connected to the neighboring VDD pin when it is being used in a 5V system. |
| NXT | Changes on this input move the motor current one step up or down in the translator table (even when the motor is disabled). The edge that triggers the step depends on the NXT-polarity configuration bit, which can be changed through the SPI interface (rising edge by default). |
| DIR | Input that determines the direction of rotation. The direction can also be controlled through the SPI interface. |
| DO | SPI data output. (This pin is also often referred to as “MISO”.) |
| DI | SPI data input. (This pin is also often referred to as “MOSI”.) |
| CLK | SPI clock input. |
| CS | SPI chip select input. Logic transitions on this pin are required for SPI communication, even if this is the only device on the SPI bus. |
| CLR | Chip reset input. A logic high on this input clears all internal registers, except in sleep mode. |
| ERR | Error output. This pin drives low to indicate that an error condition has occurred. The specific error can be determined by using the SPI interface to check the error flags. |
| POR/WD | Power-on reset/watch dog function output. This pin provides an active-low signal that can be used as a reset input for an external microcontroller. |
| SLA (filtered) | SLA (speed and load angle) output after a low-pass filter. The result is an analog voltage between 0 V and 5 V that indicates the level of the back-EMF voltage of the motor. This signal can be used for stall detection or closed-loop control of the torque and speed based on the load angle. Note: Since the output of this pin ranges from 0 V to 5 V regardless of IOREF, extra precautions should be taken when connecting this pin to a 3.3V device (such as passing it through an appropriate voltage divider). |
If you are new to the AMIS-30543 or stepper motors in general, our AMIS-30543 Arduino library can help you get started. The library provides basic functions for configuring and operating the driver using an Arduinoor Arduino-compatible controller. It also provides access to many of the driver’s advanced features and includes example sketches that show you how to use them.
The AMIS-30543 driver IC has a maximum current rating of 3 A per coil, but the actual current you can deliver depends on how well you can keep the IC cool. The carrier’s printed circuit board is designed to draw heat out of the IC, but to supply more than approximately 1.8 A per coil continuously, a heat sink or other cooling method is required. However, it is possible to use the SPI-configurable current limit to selectively deliver higher currents than this for short durations without overheating the driver.
This product can get hot enough to burn you long before the chip overheats. Take care when handling this product and other components connected to it.
Please note that measuring the current draw at the power supply will generally not provide an accurate measure of the coil current. Since the input voltage to the driver can be significantly higher than the coil voltage, the measured current on the power supply can be quite a bit lower than the coil current (the driver and coil basically act like a switching step-down power supply). Also, if the supply voltage is very high compared to what the motor needs to achieve the set current, the duty cycle will be very low, which also leads to significant differences between average and RMS currents.
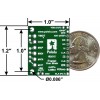
| Size: | 1.0″ × 1.2″ |
|---|---|
| Weight: | 4.0 g1 |
| Minimum operating voltage: | 6 V2 |
|---|---|
| Maximum operating voltage: | 30 V |
| Continuous current per phase: | 1.8 A3 |
| Maximum current per phase: | 3 A4 |
| Minimum logic voltage: | 2.5 V |
| Maximum logic voltage: | 5.5 V |
| Microstep resolutions: | full, 1/2, 1/4, 1/8, 1/16, 1/32, 1/64, 1/128 |
| Reverse voltage protection?: | Y |
Data sheet
Manufacturer
Responsible person
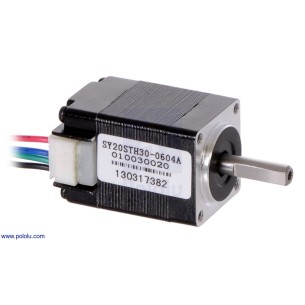
Bipolar stepper motor. It has a resolution of 200 steps/revolution (1.8° per step), a rated voltage of 3.9 V, and draws a current of 0.6 A per coil. Pololu 1204
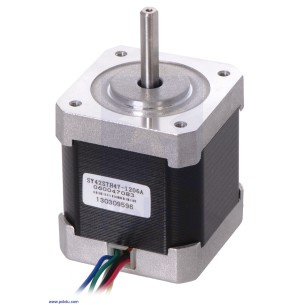
Bipolar stepper motor. It has a resolution of 200 steps/revolution (1.8° per step), has a nominal voltage of 4 V and draws a current of 1.2 A per coil. Pololu 1200
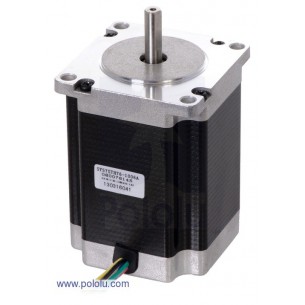
Unipolar/bipolar stepper motor. It has a resolution of 200 steps/revolution (1.8° per step), has a nominal voltage of 8.6 V, and draws a current of 1 A per coil. Pololu 1477
No product available!
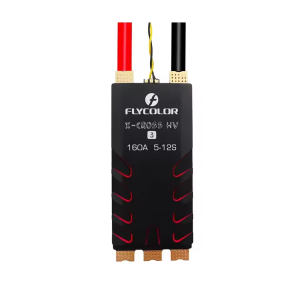
Flycolor X-Cross HV3 160A ESC designed to control brushless motors in multirotor RC models and large FPV platforms. It supports 5-12S LiPo batteries, up to 160 A continuous current and 180 A burst current, while BLHeli-32 firmware provides support for digital and analog control protocols. Flycolor X-Cross HV3 160A
ESC controller module for a brushless motor with a current capacity of up to 80 A. It can work with LiPo packs from 5S to 12S. Uses BLHeli_32 software. FLYCOLOR X-CROSS HV
Programming module for AM32 and BLS32 series ESC controllers. It allows you to easily update the controller software via the USB Type-C connector. RhinoESC Crawler
The UX-52 panel brush motor speed controller is a versatile device with speed adjustment from 90 to 1400 rpm. It offers precise control of motors with an input voltage of 220VAC, featuring a solid construction and a convenient digital display.
The 7A 1-2S BLheli_S XSD7A Miniature Brushless Motor ESC Controller is a compact, high-performance device ideal for controlling brushless motors in small projects. Thanks to its low weight and solid power, it is suitable for drones, RC models and other applications requiring precise motor control.
A controller that allows you to control any 3-phase BLDC motor. It is equipped with built-in WiFi and Bluetooth connectivity as well as an integrated TMAG5273 Hall effect sensor and INA240A1 current sensor amplifiers, thanks to which it allows the use of advanced FOC algorithms. SparkFun ROB-22132
Module with a stepper motor driver based on the DRV8434 system. It allows you to power a bipolar motor with a current of up to 1.2 A per phase and a voltage from 4.5 V to 48 V. Pololu 3762
Module with a stepper motor driver based on the DRV8434 system. It allows you to power a bipolar motor with a current of up to 1.2 A per phase and a voltage from 4.5 V to 48 V. Pololu 3763
Module with a stepper motor driver based on the DRV8834 system. It allows you to power a bipolar motor with a current of up to 2 A per phase, without using a heat sink. The system can be powered with a voltage of up to 10.8 V. Pololu 2134
KAmod Motor Driver is an advanced DC motor controller powered by 6-30 V, enabling power regulation using the PWM method and control of the direction of rotation, compatible with analog and PWM signals from various sources, equipped with overload and thermal protections and soft start and stop functions
This advanced Nema 23 stepper motor controller from the CLRS series is designed for precision industrial applications with RS485 (Modbus RTU) network communication. It eliminates the risk of lost steps with closed-loop feedback and offers support for Profile Position, Velocity, Homing, and PR Mode with a 16-position point-to-point control table. The controller supports up to 31 axes on a single network, offers up to 7 A current, a 20 to 50 VDC supply voltage, and passive or active cooling, making it a reliable solution for robotics, automation, and CNC systems. CL2C-RS57
A compact controller that enables precise control of bipolar stepper motors. It offers high precision movement thanks to the ability to control a stepper motor with a resolution of up to 1/128 steps and two control interfaces - clock-in step control and serial commands. SparkFun ROB-25167
Compact and efficient module designed for precise control of bipolar stepper motors, offering microstepping down to 1/32 step and maximum current up to 2 A in peak mode. Thanks to advanced features such as QuietStep (APFD) algorithm, built-in protections and pin compatibility with A4988, it is perfect for hobby, educational and industrial projects. Blue Edition version with four-layer board and 2 oz copper provides better heat dissipation, increasing reliability of operation even at higher loads. Pololu 5340
Compact and efficient module designed for precise control of bipolar stepper motors, offering microstepping down to 1/32 step and maximum current up to 2 A in peak mode. Thanks to advanced features such as QuietStep (APFD) algorithm, built-in protections and pin compatibility with A4988, it is perfect for hobby, educational and industrial projects. Blue Edition version with four-layer board and 2 oz copper provides better heat dissipation, increasing reliability of operation even at higher loads. Pololu 5341
Driver for bipolar stepper motors with STEP/DIR interface, microstepping up to 1/16 and adjustable current via onboard potentiometer, compatible with 3.3 V and 5 V logic, version without soldered headers. Pololu 5342
Driver for bipolar stepper motors with STEP/DIR interface, microstepping up to 1/16 and adjustable current via onboard potentiometer, compatible with 3.3 V and 5 V logic, includes soldered header pins. Pololu 5343
This is a breakout board for ON Semiconductor’s AMIS-30543 microstepping bipolar stepper motor driver, which features SPI-adjustable current limiting, 11 step modes (from full-step through 1/128-step), back-EMF feedback that can be used for stall detection or optional closed-loop control, and over-current and over-temperature protection.